My publications can also be found on Google Scholar.
2026
-
Preprint 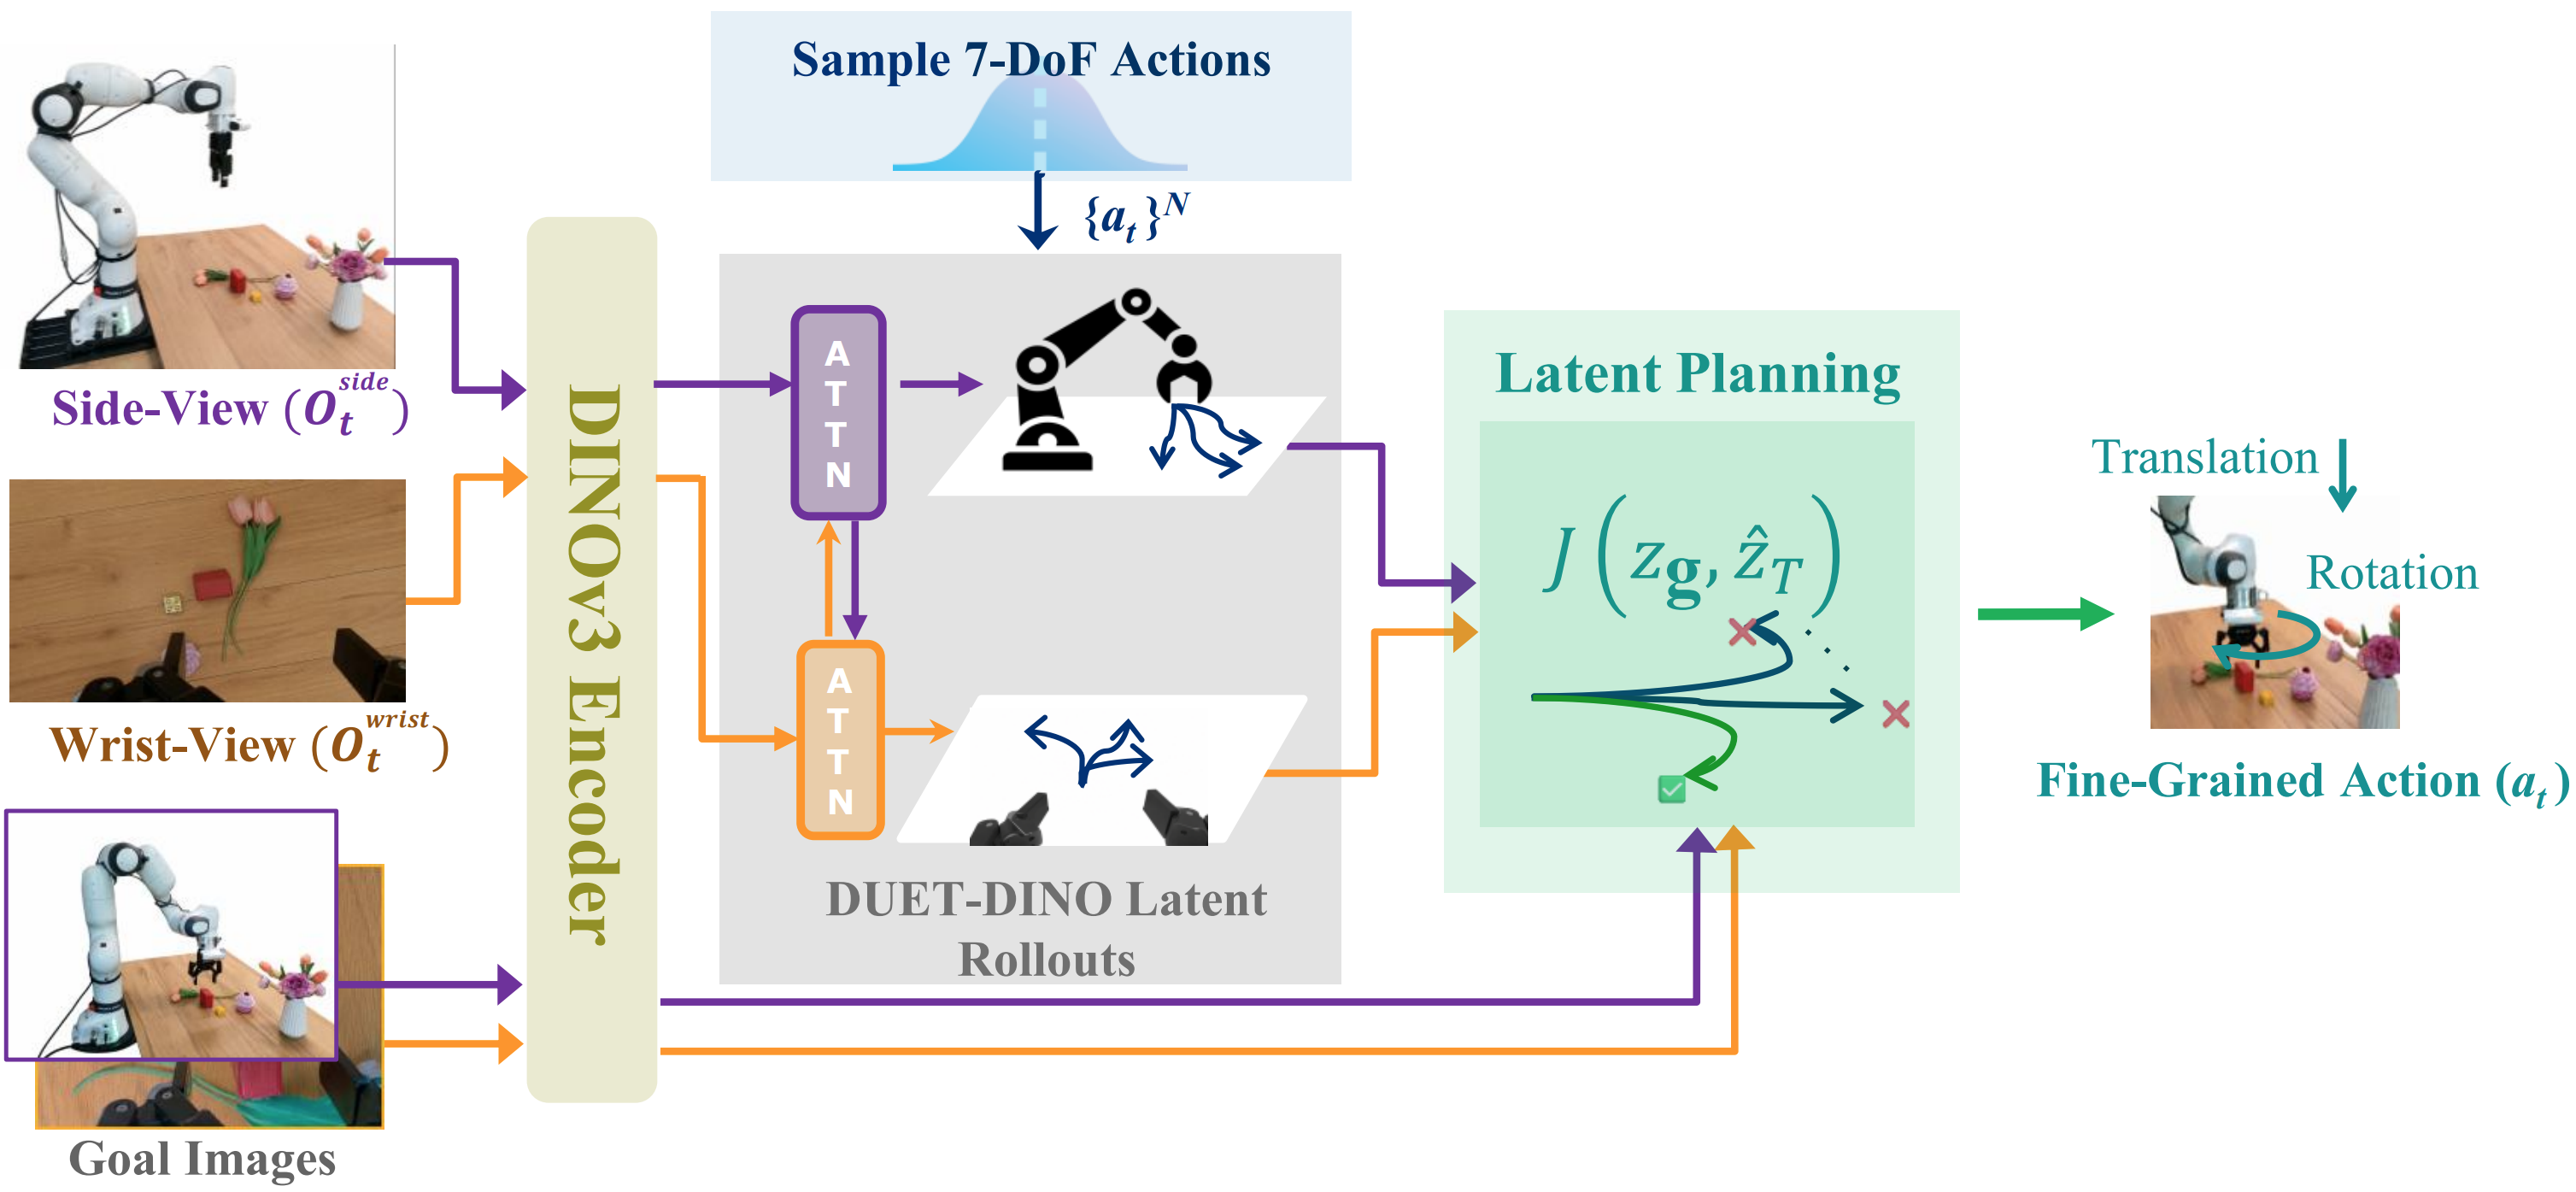
DUET-DINO: Simultaneous Cross-View World Modeling for Latent Planning in Robot Manipulation
Nisarga Nilavadi, Ralf Römer, Moritz Reuss, Michael Krawez, Tobias Jülg, Angela P. Schoellig, Rudolf Lioutikov, and Wolfram Burgard
arXiv preprint, 2026
-
Preprint 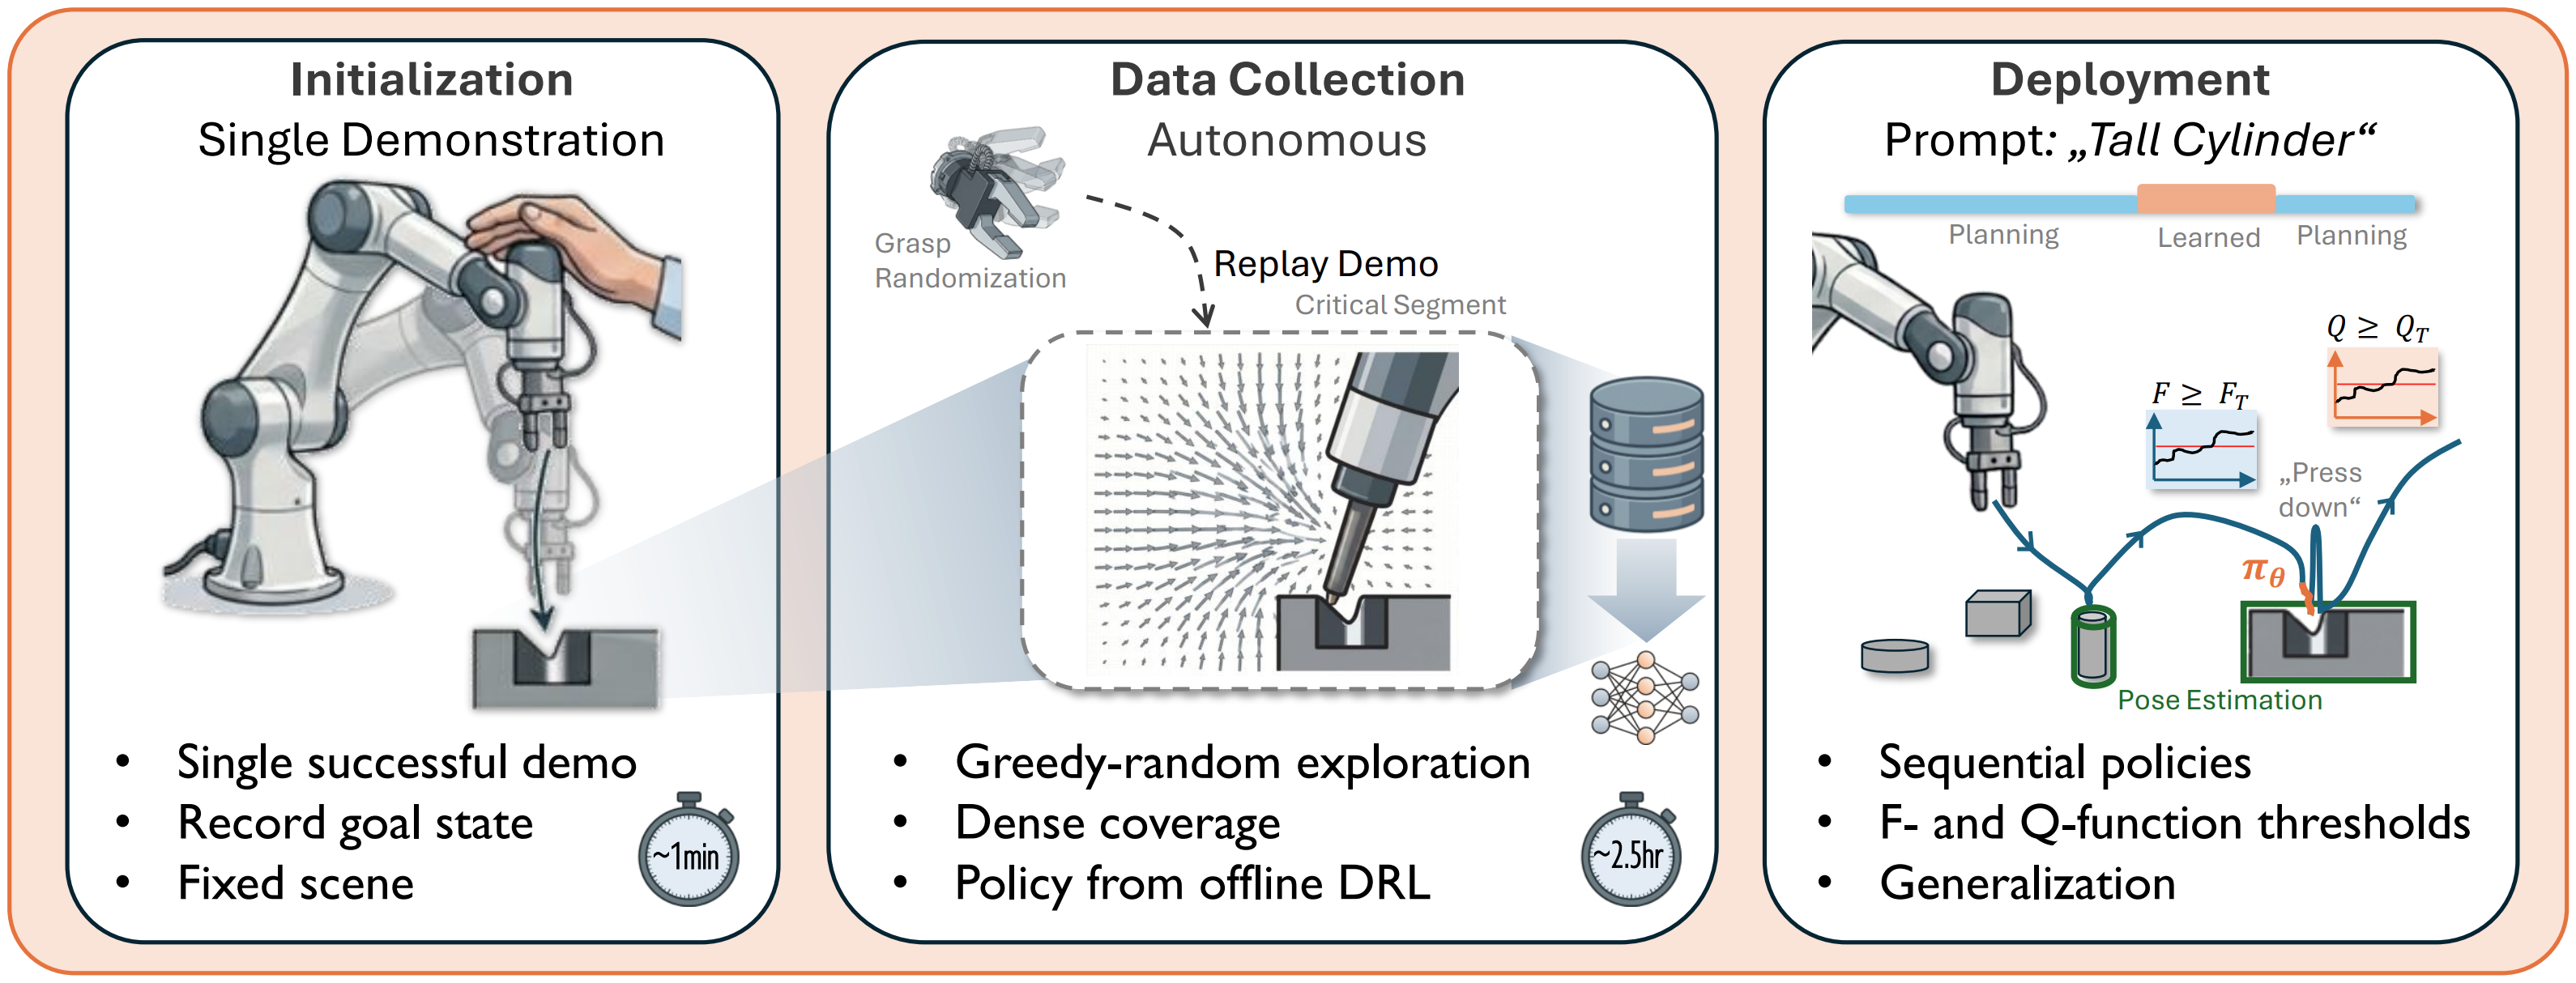
Data and Learning Where it Matters for Contact-Rich Manipulation
Oliver Hausdörfer, Linus Schwarz, Gabor Marko, Christian Dietz, Timo Class, Luka Hofer, Jim Yun-Jin Li, Johannes Hechtl, and 2 more authors
arXiv preprint, 2026
-
Preprint 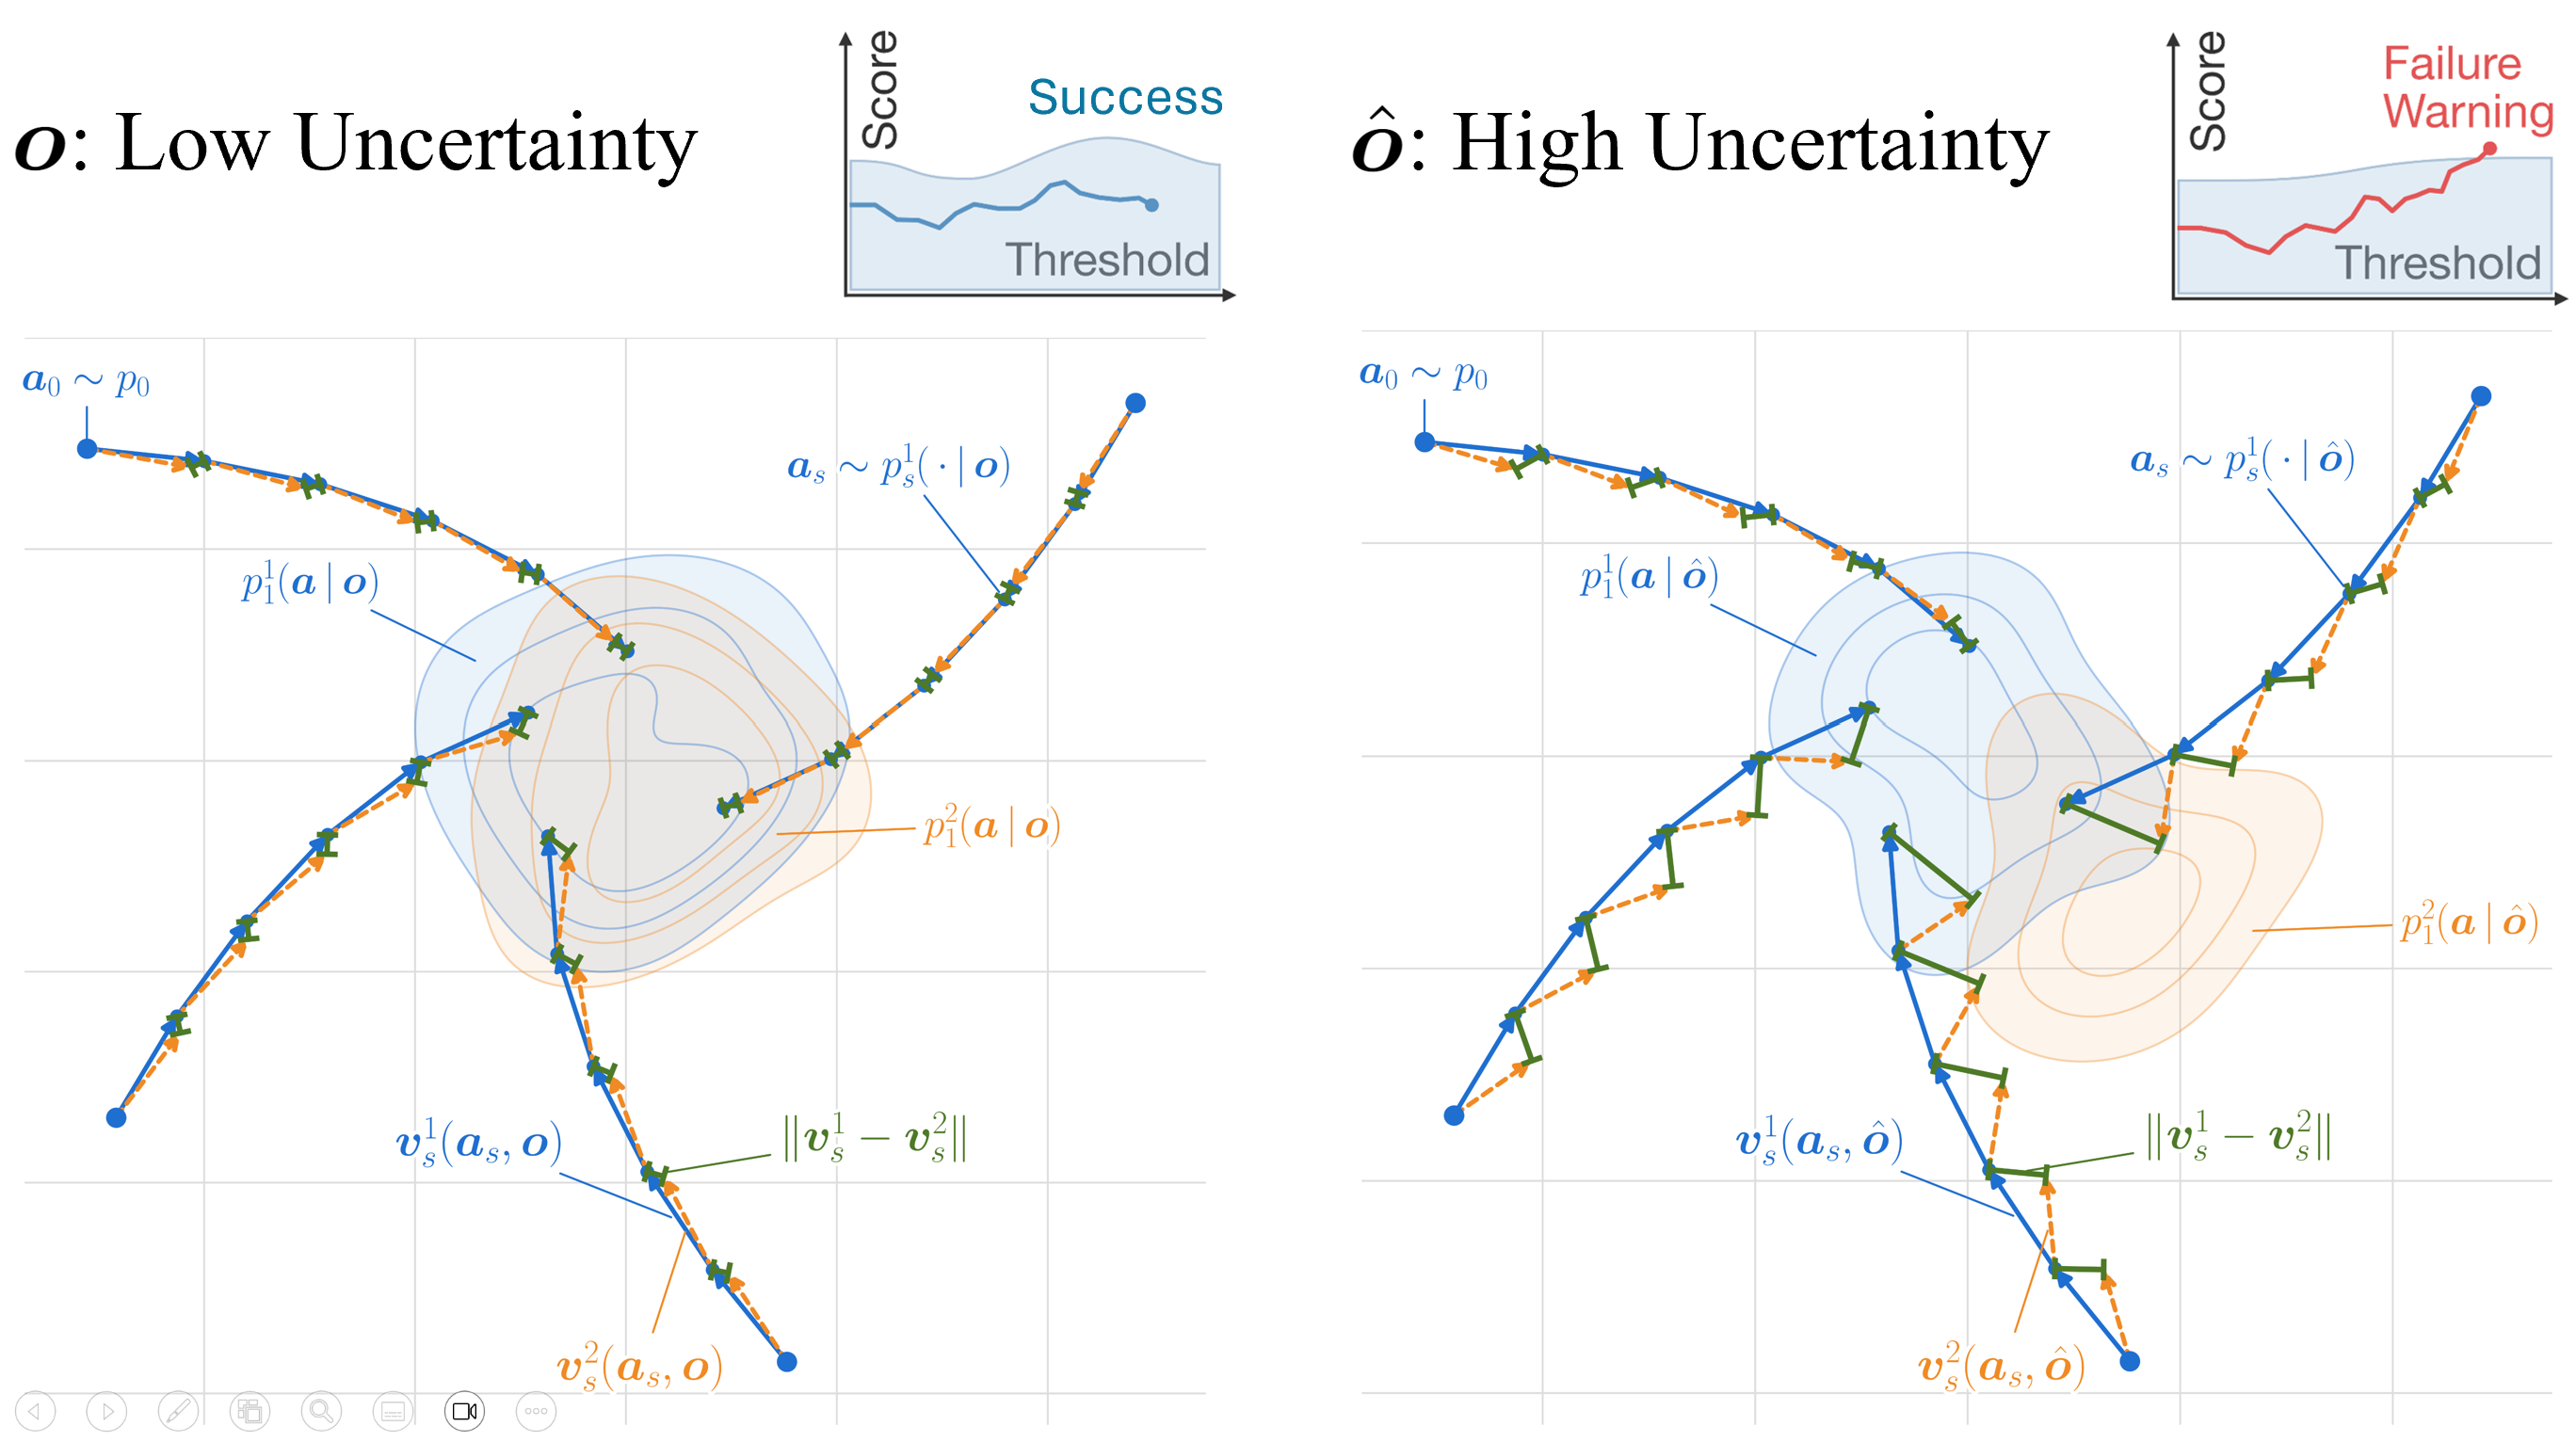
Uncertainty Quantification for Flow-Based Vision-Language-Action Models
Ralf Römer, Maximilian Seeliger, Saida Liu, Ben Sturgis, Marco Bagatella, Daniel Marta, Andreas Krause, and Angela P. Schoellig
arXiv preprint, 2026
-
RA-L 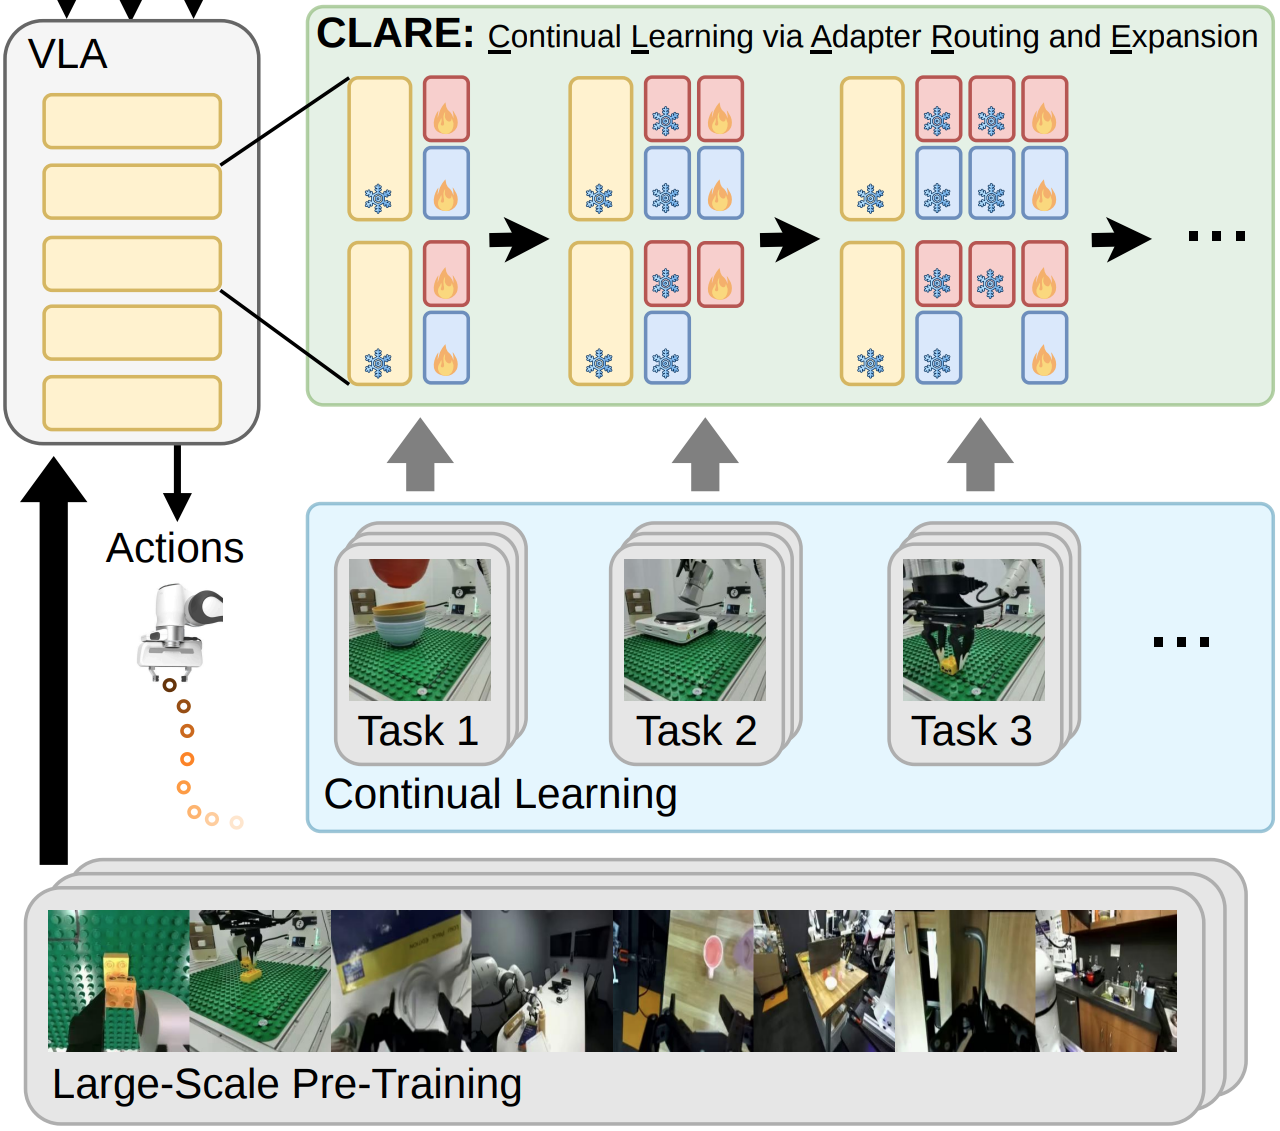
CLARE: Continual Learning for Vision-Language-Action Models via Autonomous Adapter Routing and Expansion
Ralf Römer*, Yi Zhang*, Yuming Li, and Angela P. Schoellig
IEEE Robotics and Automation Letters (RA-L), 2026
-
ICRA 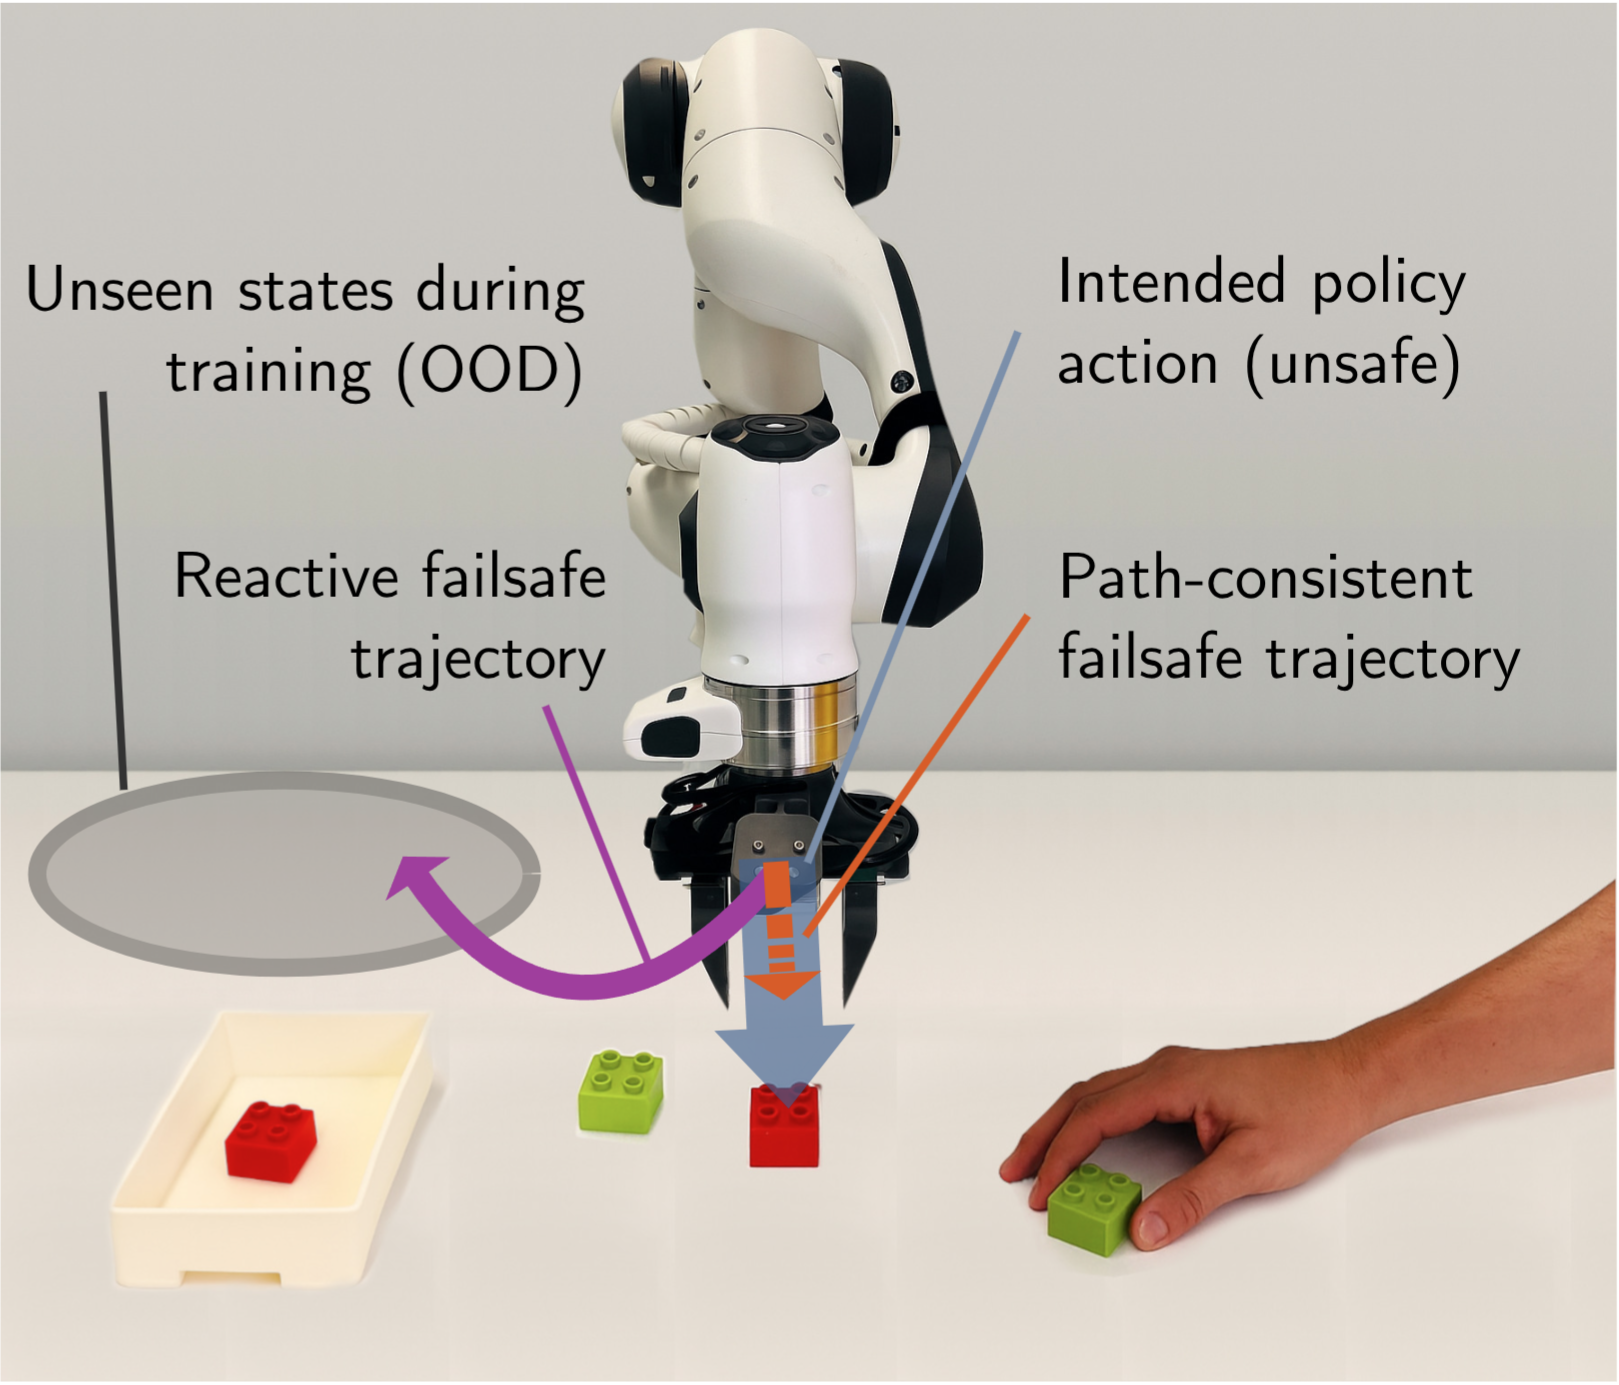
From Demonstrations to Safe Deployment: Path-Consistent Safety Filtering for Diffusion Policies
Ralf Römer*, Julian Balletshofer*, Jakob Thumm, Marco Pavone, Angela P. Schoellig, and Matthias Althoff
In IEEE International Conference on Robotics and Automation (ICRA), 2026
-
RA-P 
CRISP - Compliant ROS2 Controllers for Learning-Based Manipulation Policies and Teleoperation
Daniel San José Pro, Oliver Hausdörfer, Ralf Römer, Maximilian Dösch, Martin Schuck, and Angela P. Schoellig
IEEE Robotics and Automation Practice (RA-P), 2026
2025
-
NeurIPS 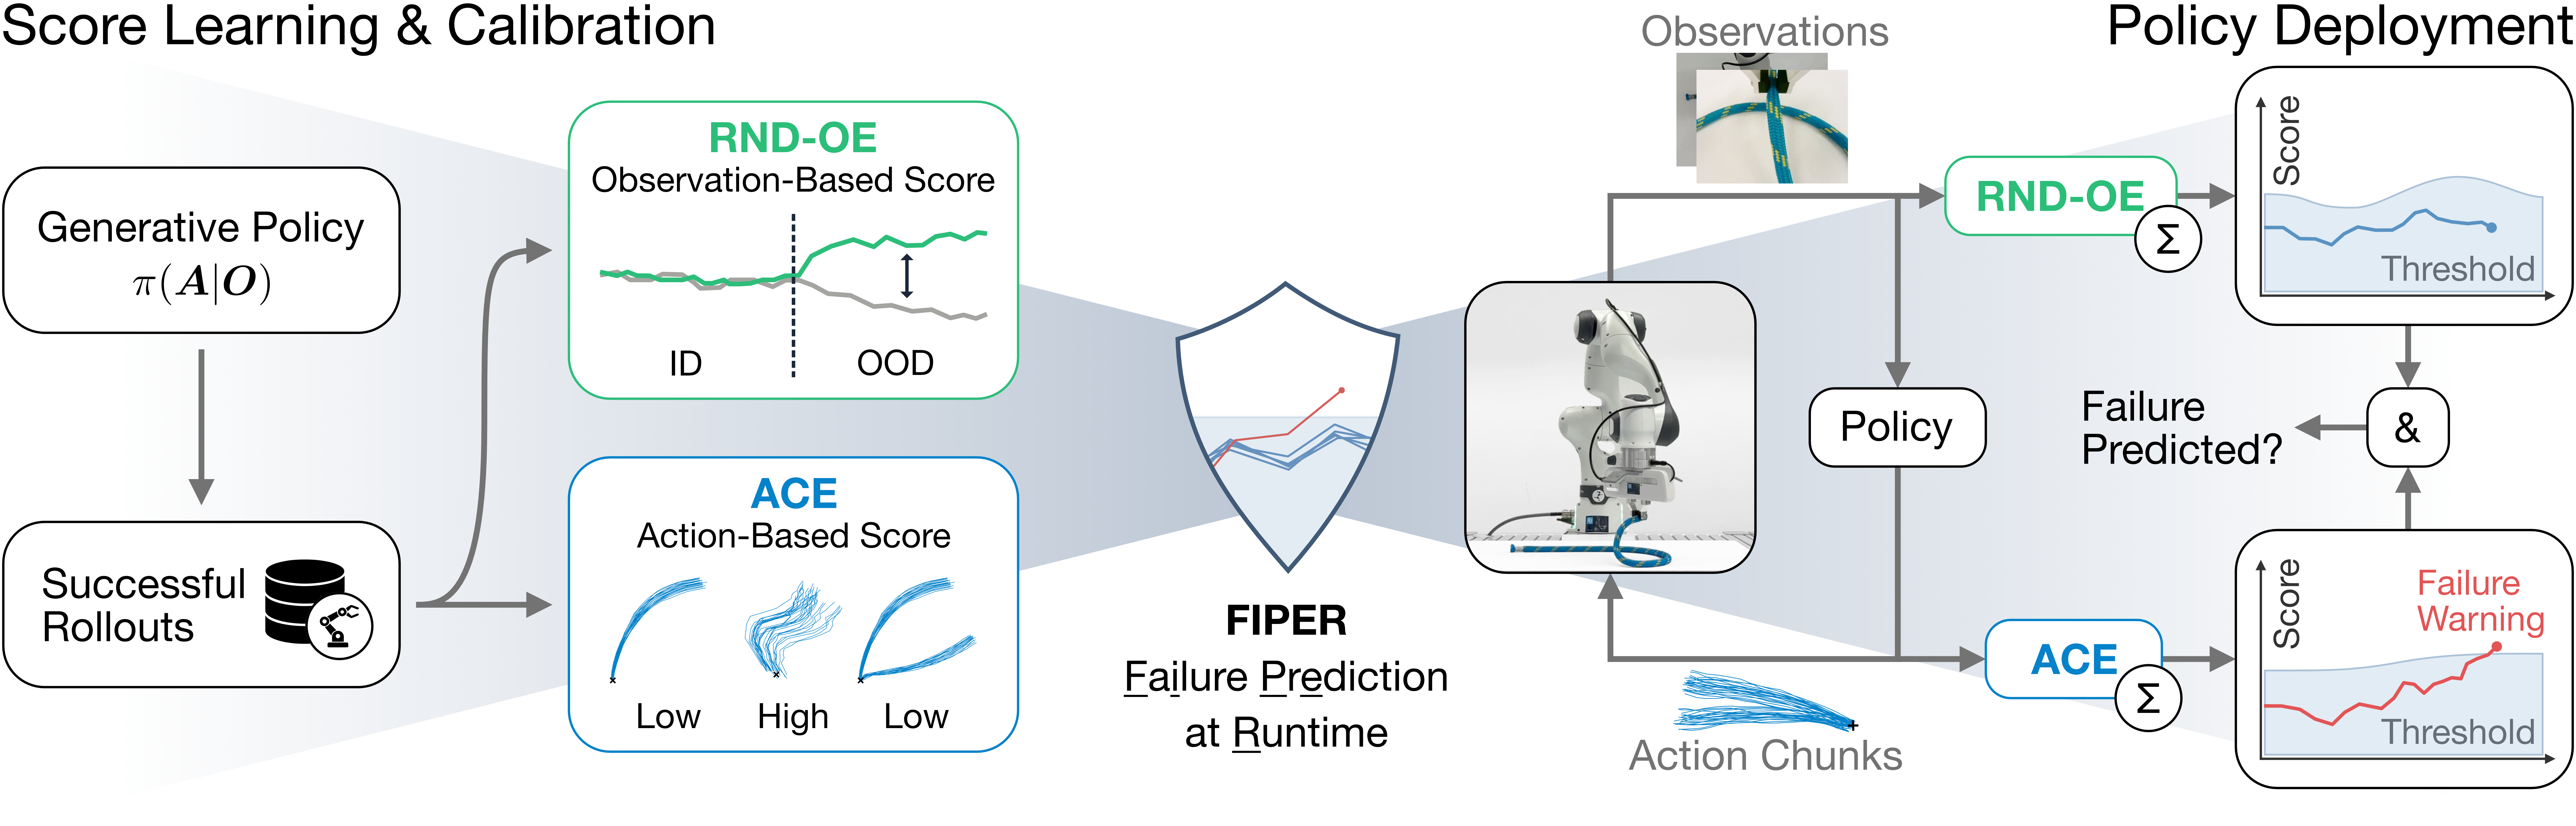
Failure Prediction at Runtime for Generative Robot Policies
Ralf Römer*, Adrian Kobras*, Luca Worbis, and Angela P. Schoellig
In Advances in Neural Information Processing Systems (NeurIPS), 2025
-
Preprint 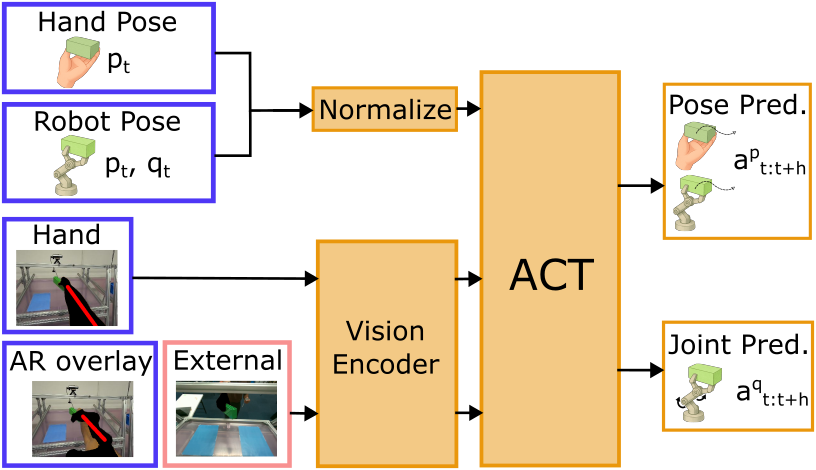
ARMimic: Learning Robotic Manipulation from Passive Human Demonstrations in Augmented Reality
Rohan Walia, Yusheng Wang, Ralf Römer, Masahiro Nishio, Angela P. Schoellig, and Jun Ota
arXiv preprint, 2025
-
L4DC 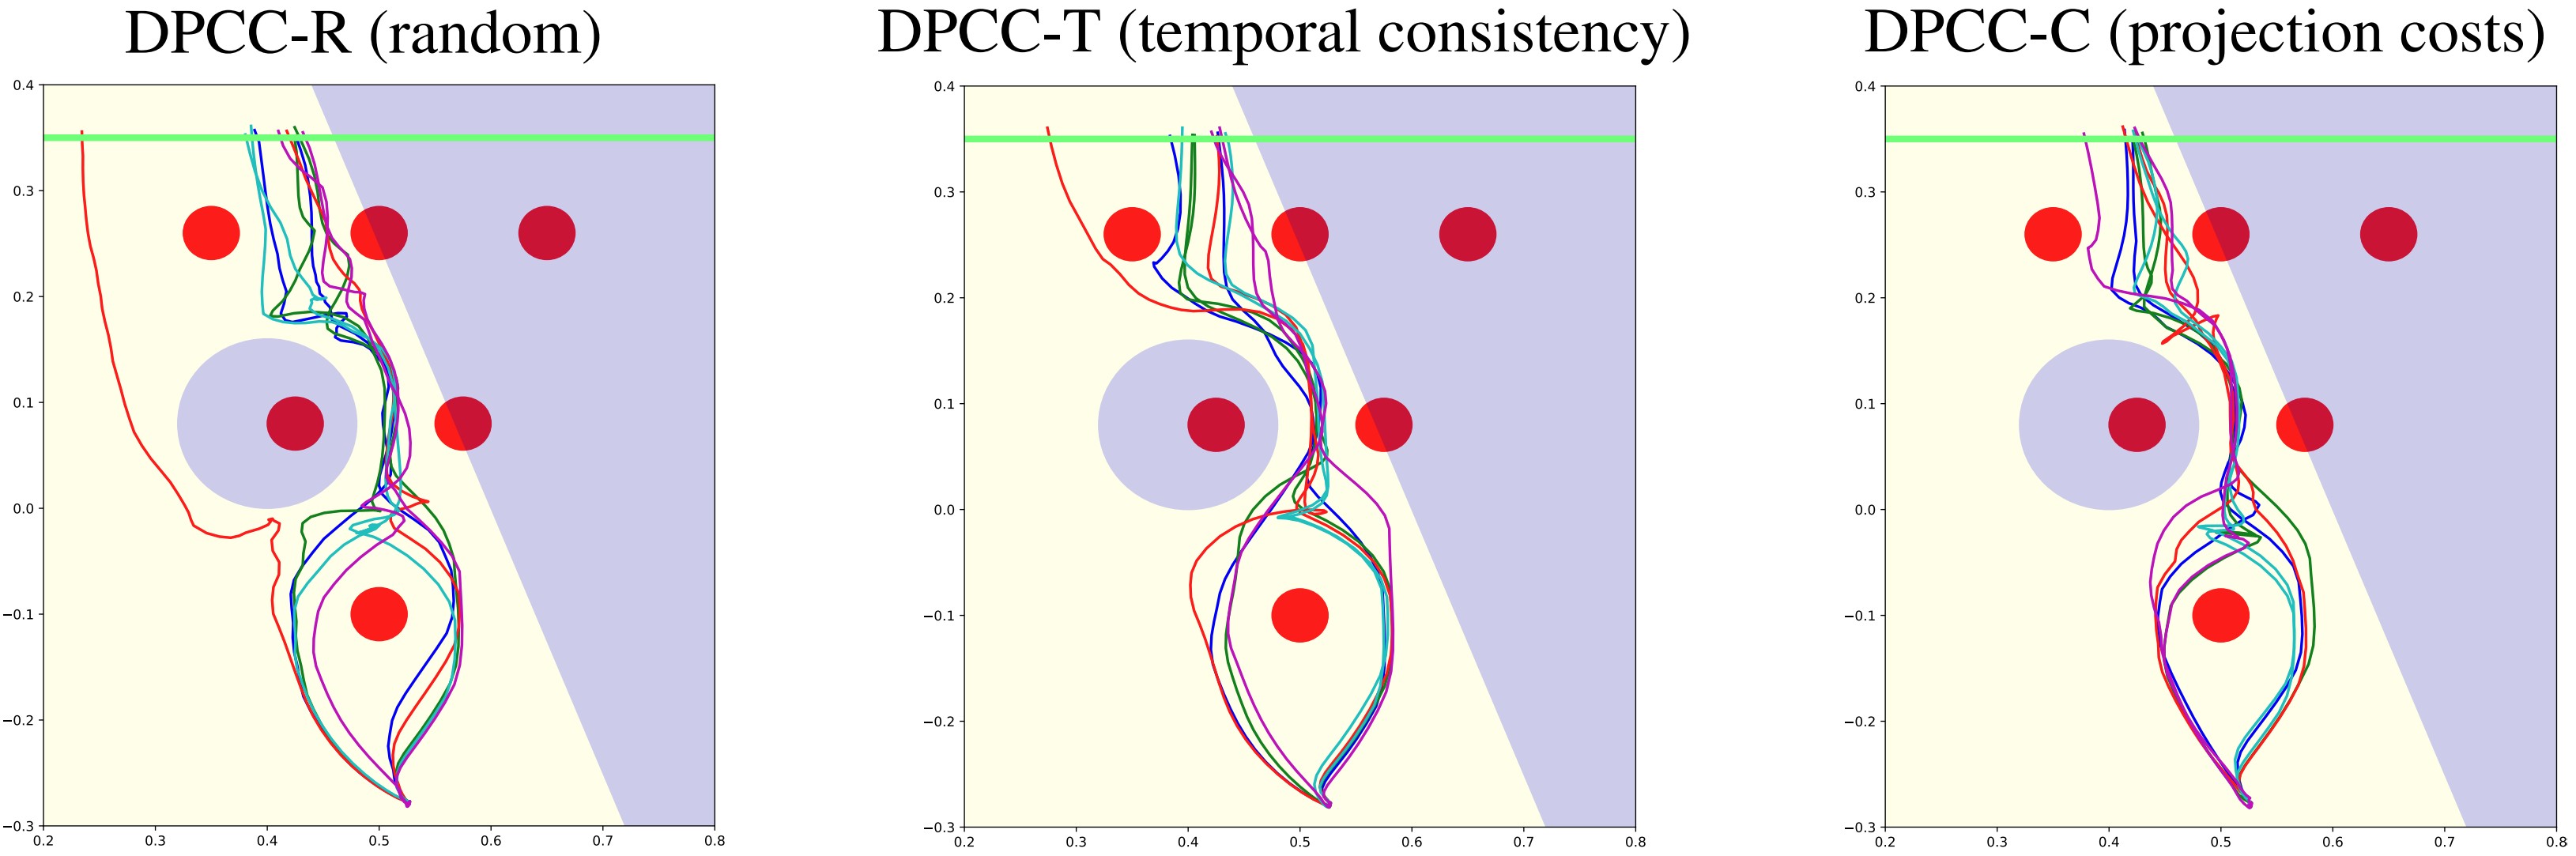
Diffusion Predictive Control with Constraints
Ralf Römer, Alexander Rohr, and Angela P. Schoellig
In Learning for Dynamics and Control Conference (L4DC), 2025
-
ICRA 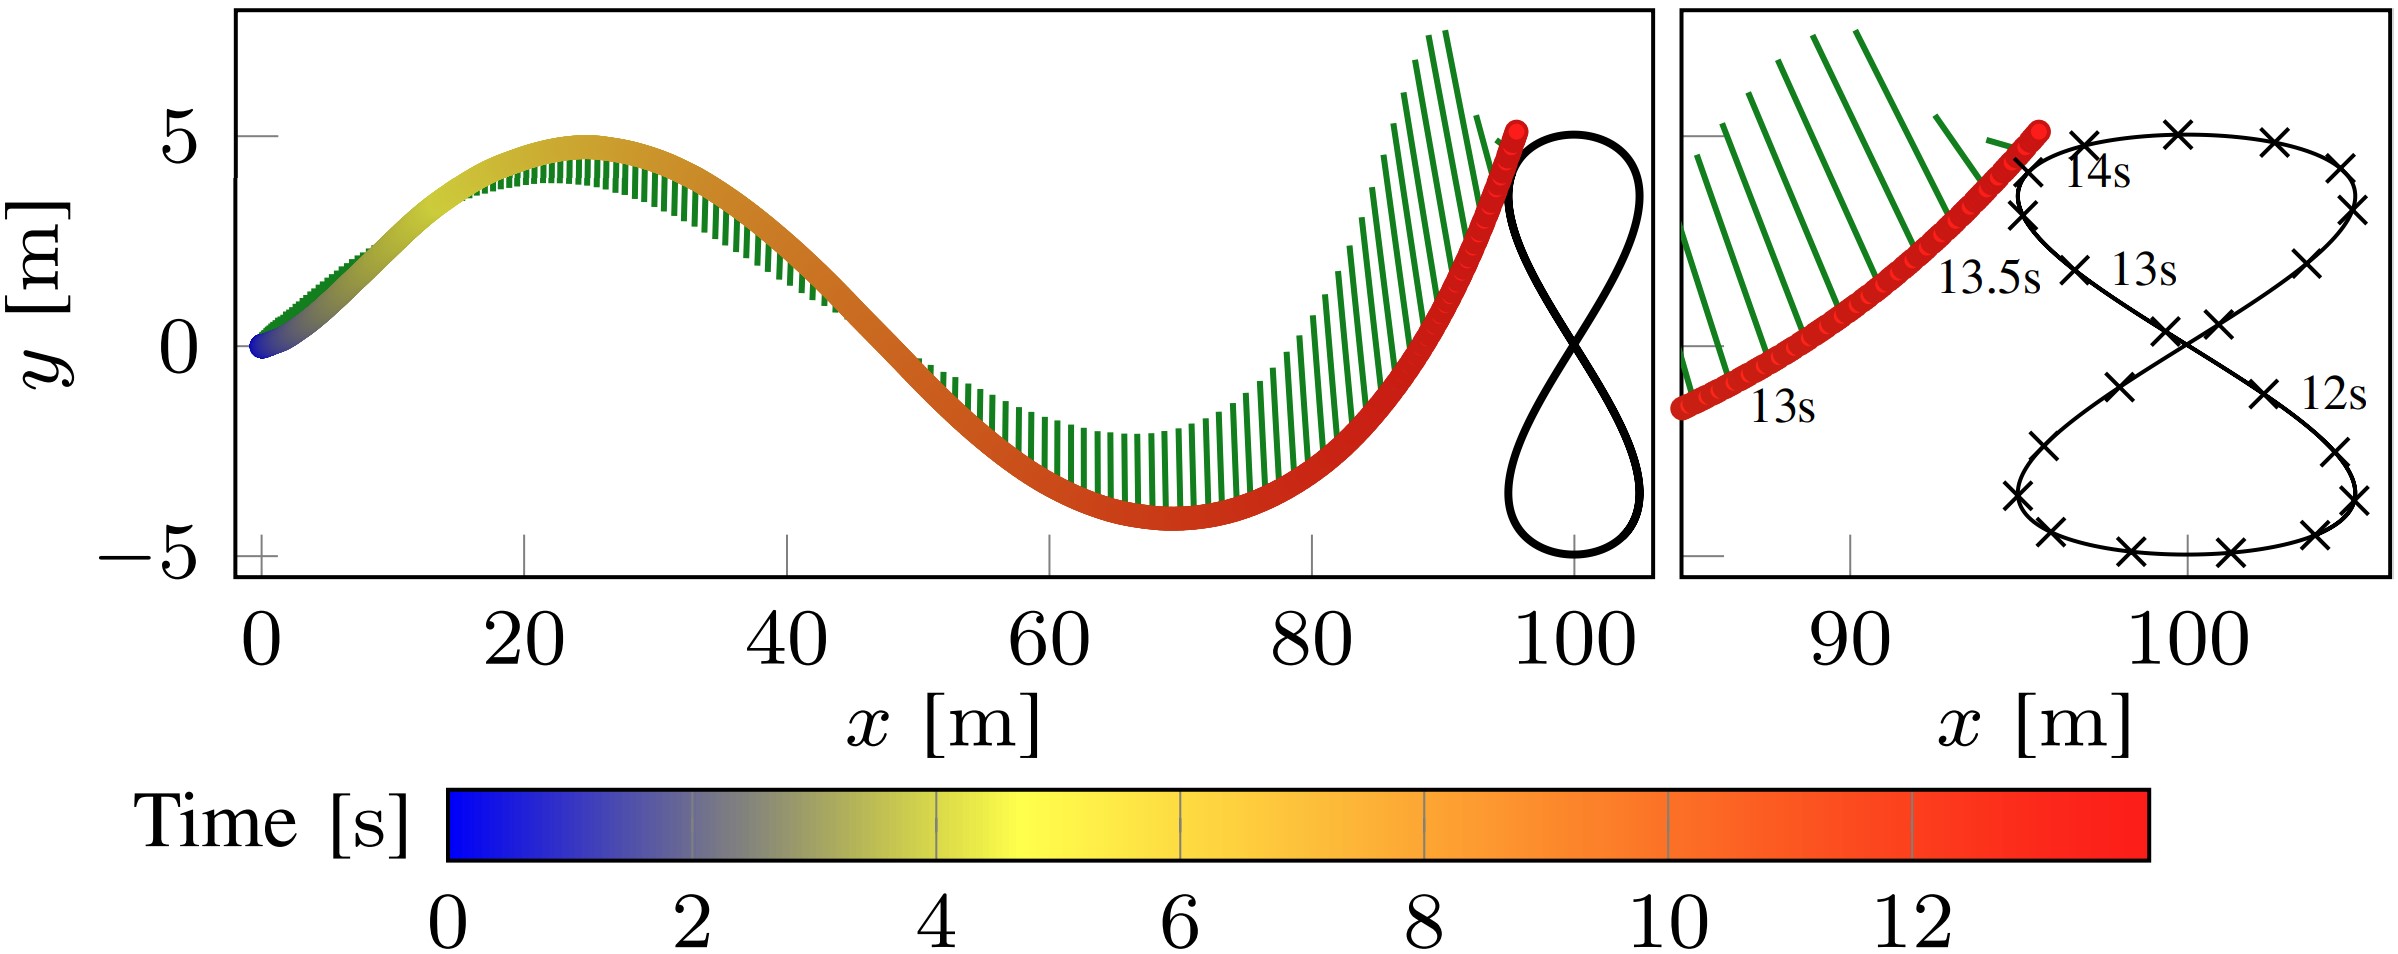
Flying through Moving Gates without Full State Estimation
Ralf Römer, Tim Emmert, and Angela P. Schoellig
In IEEE International Conference on Robotics and Automation (ICRA), 2025
-
RA-L 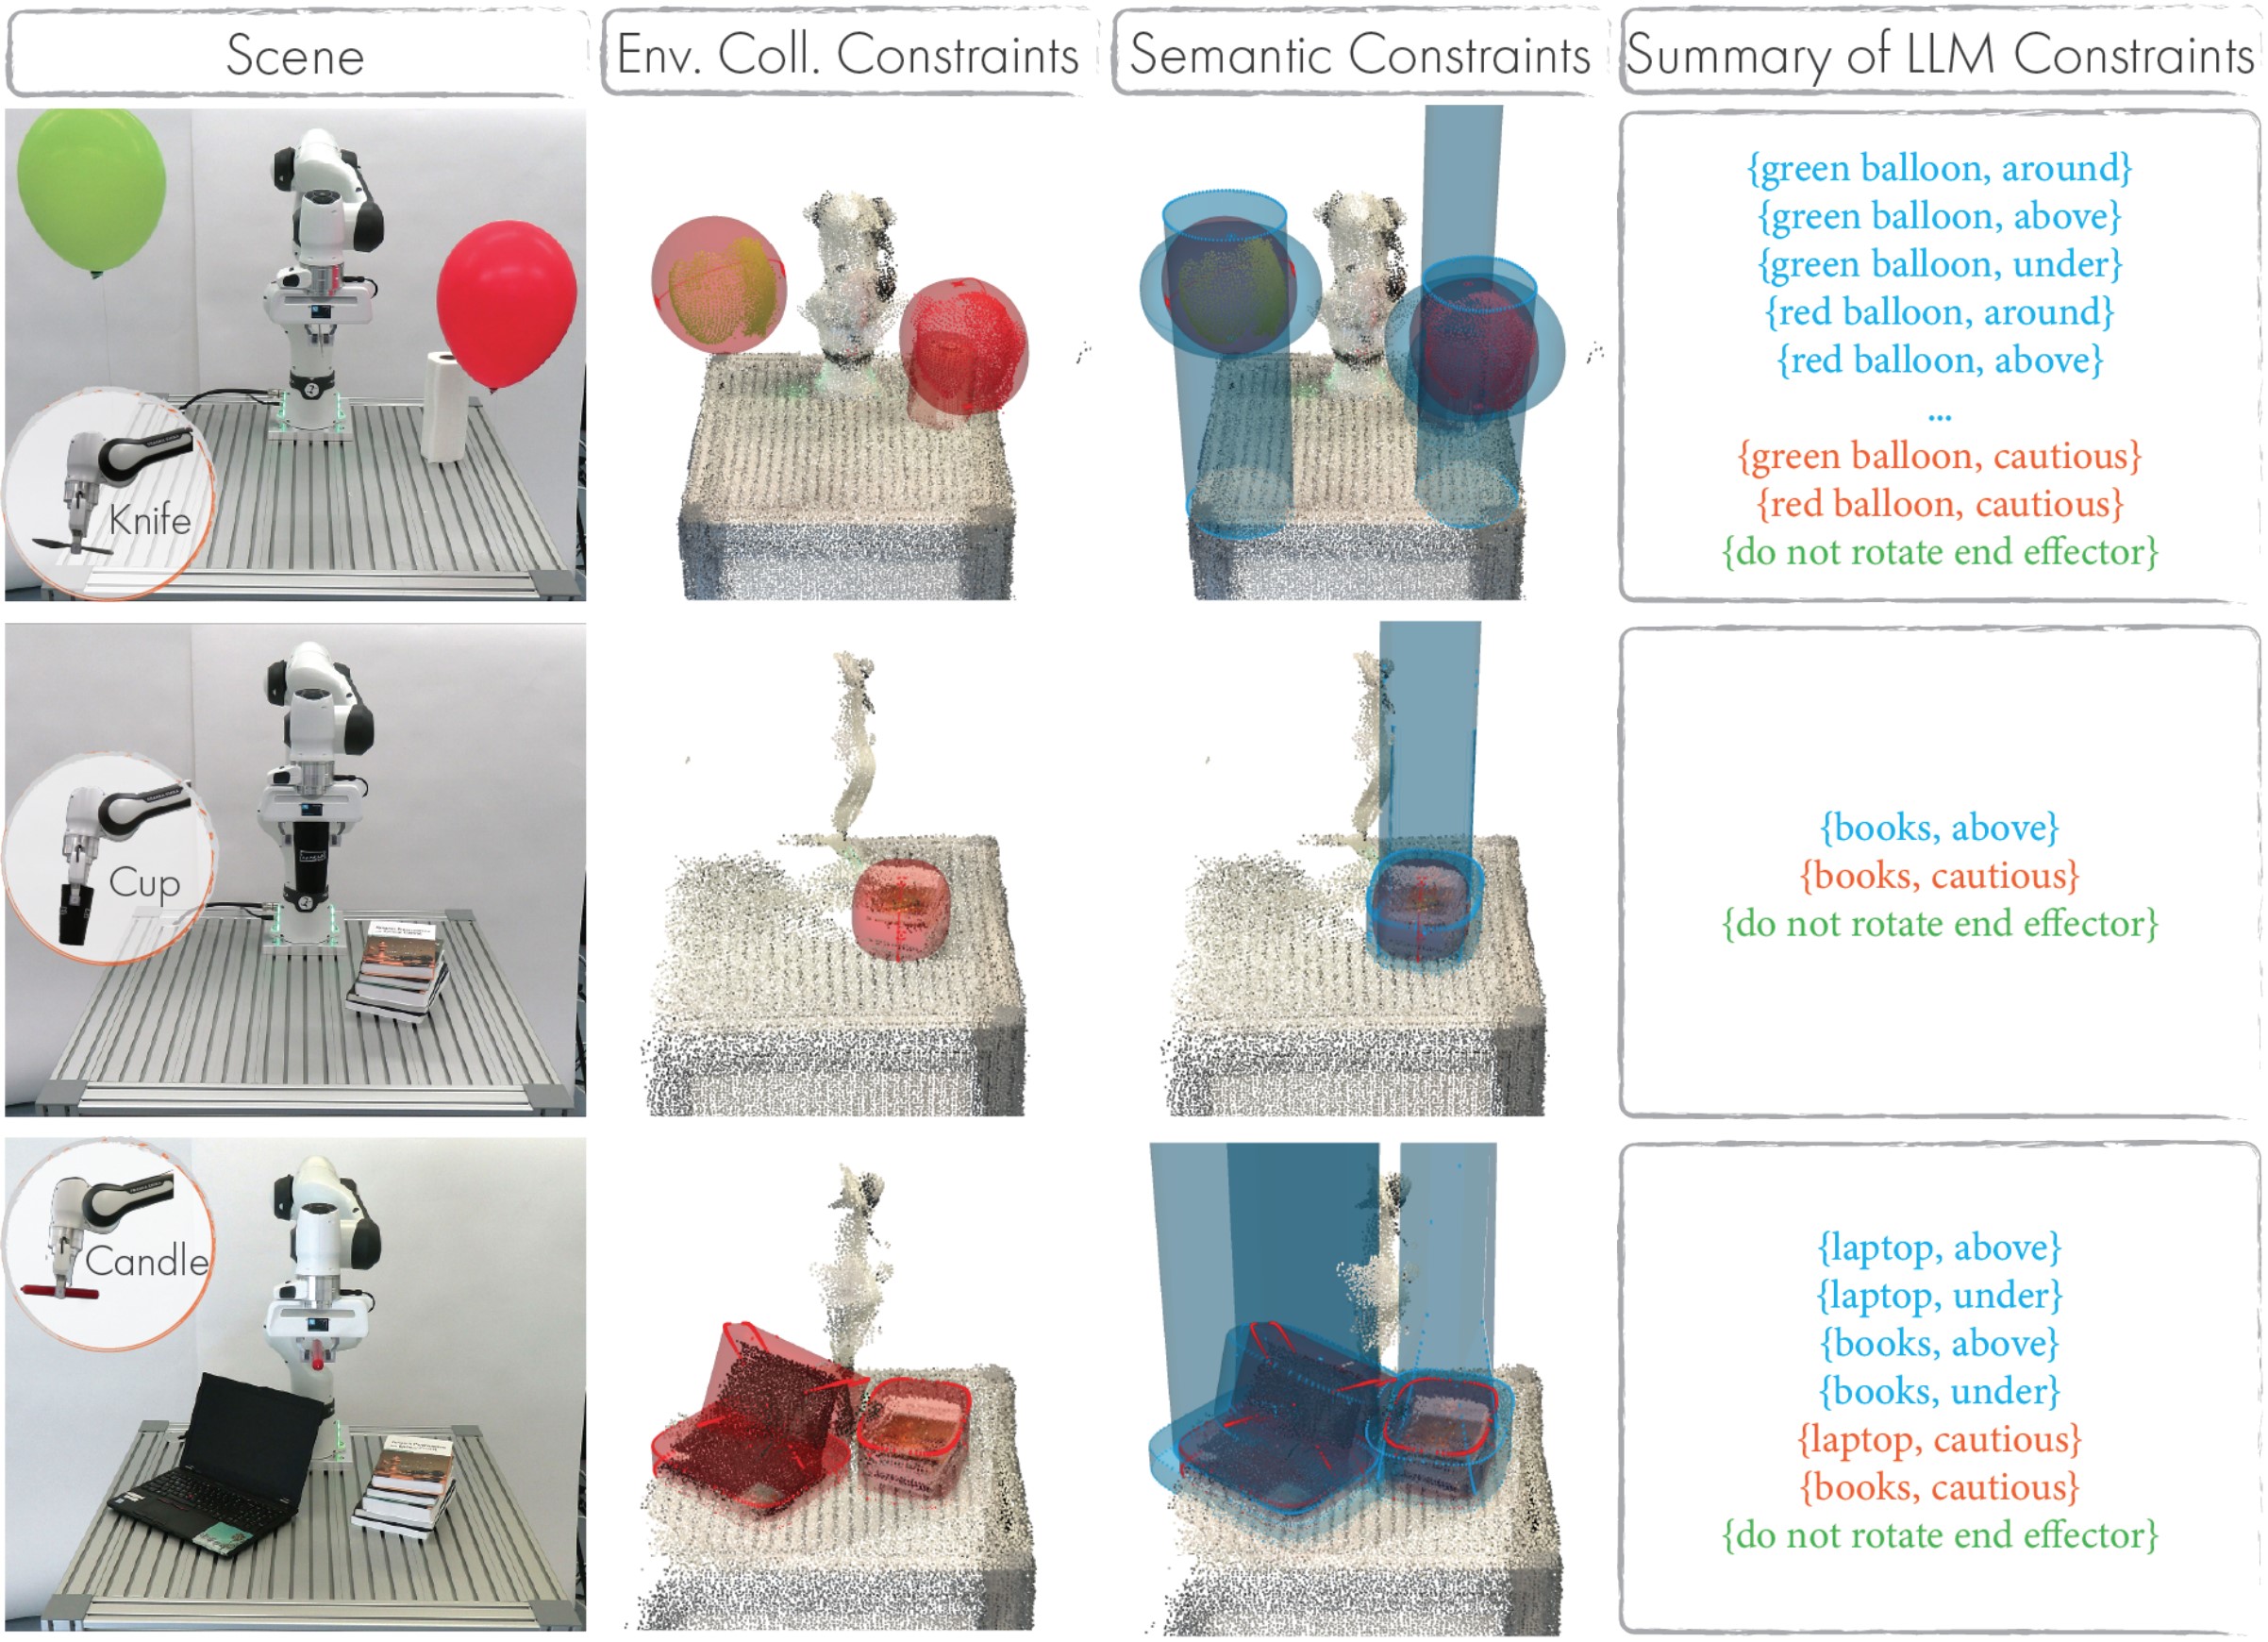
Semantically Safe Robot Manipulation: From Semantic Scene Understanding to Motion Safeguards
Lukas Brunke, Yanni Zhang, Ralf Römer, Jack Naimer, Nikola Staykov, Siqi Zhou, and Angela P. Schoellig
IEEE Robotics and Automation Letters (RA-L), 2025
2024
-
ACC 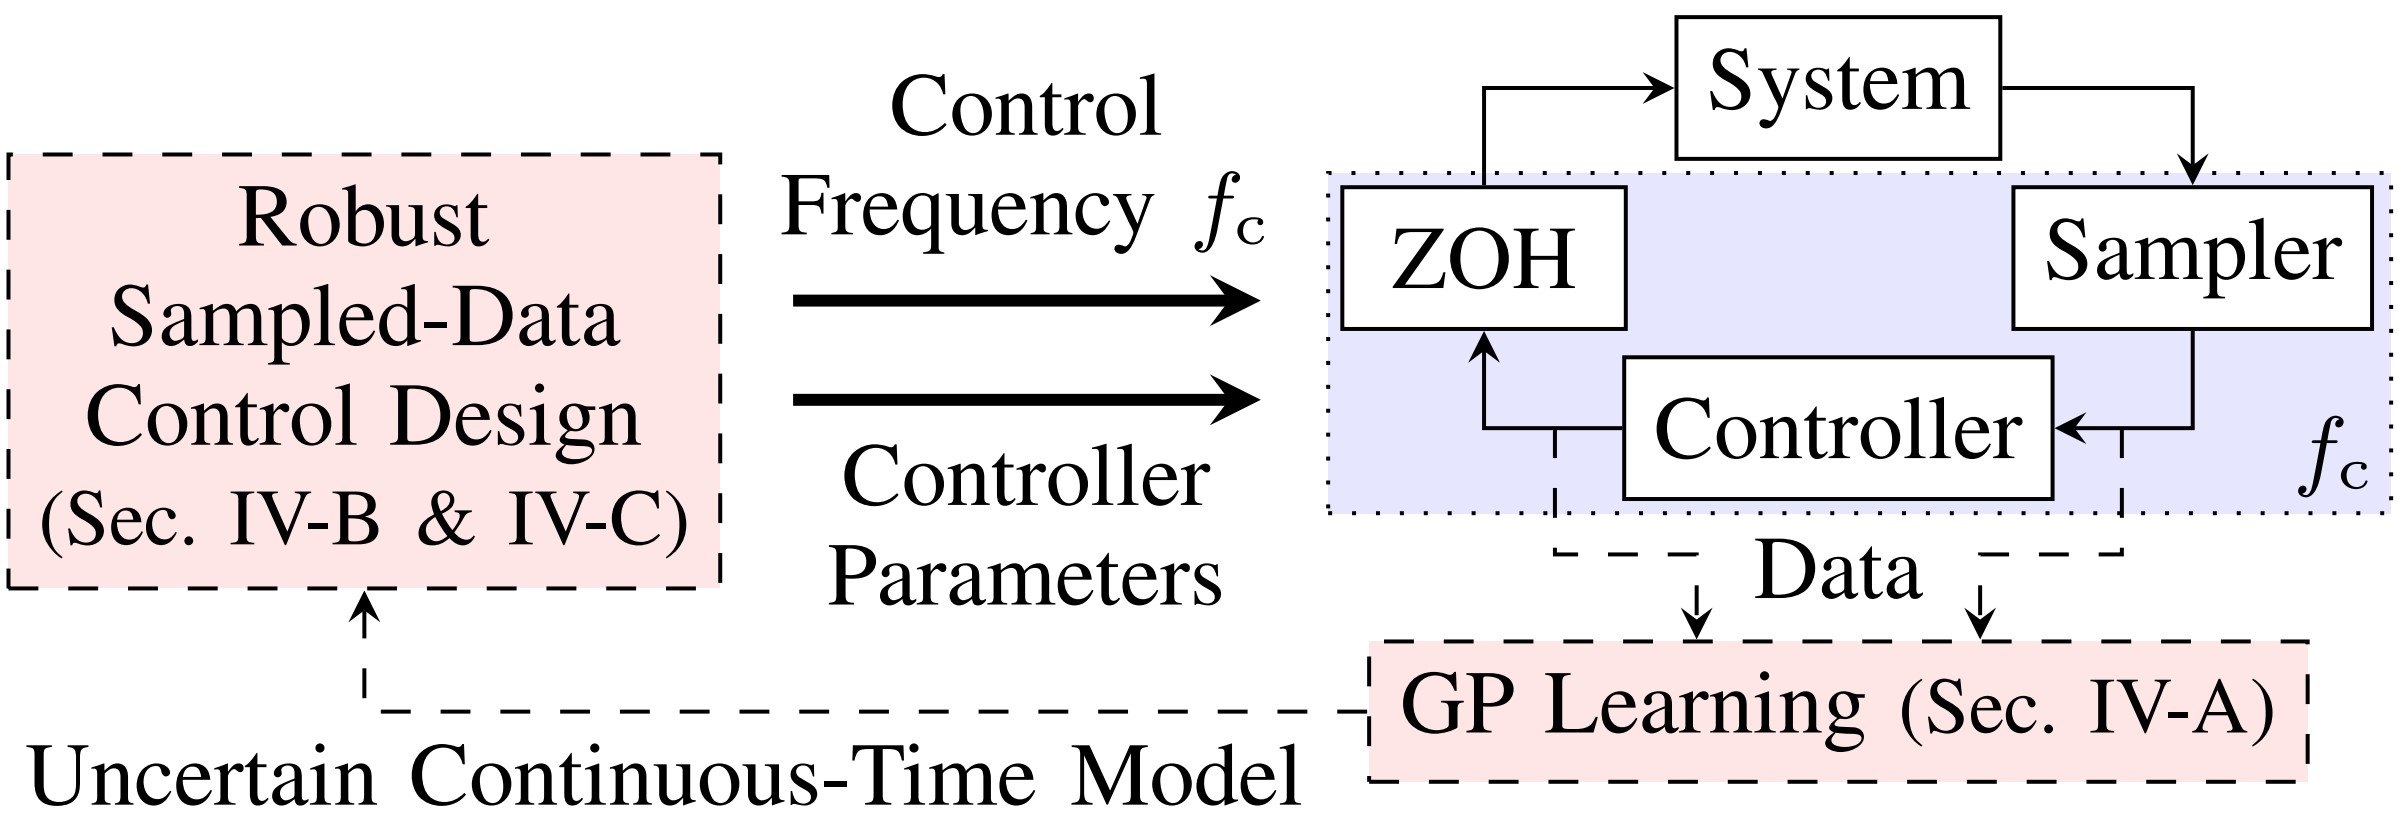
Is Data All That Matters? The Role of Control Frequency for Learning-Based Sampled-Data Control of Uncertain Systems
Ralf Römer, Lukas Brunke, Siqi Zhou, and Angela P. Schoellig
In American Control Conference (ACC), 2024
-
Workshop 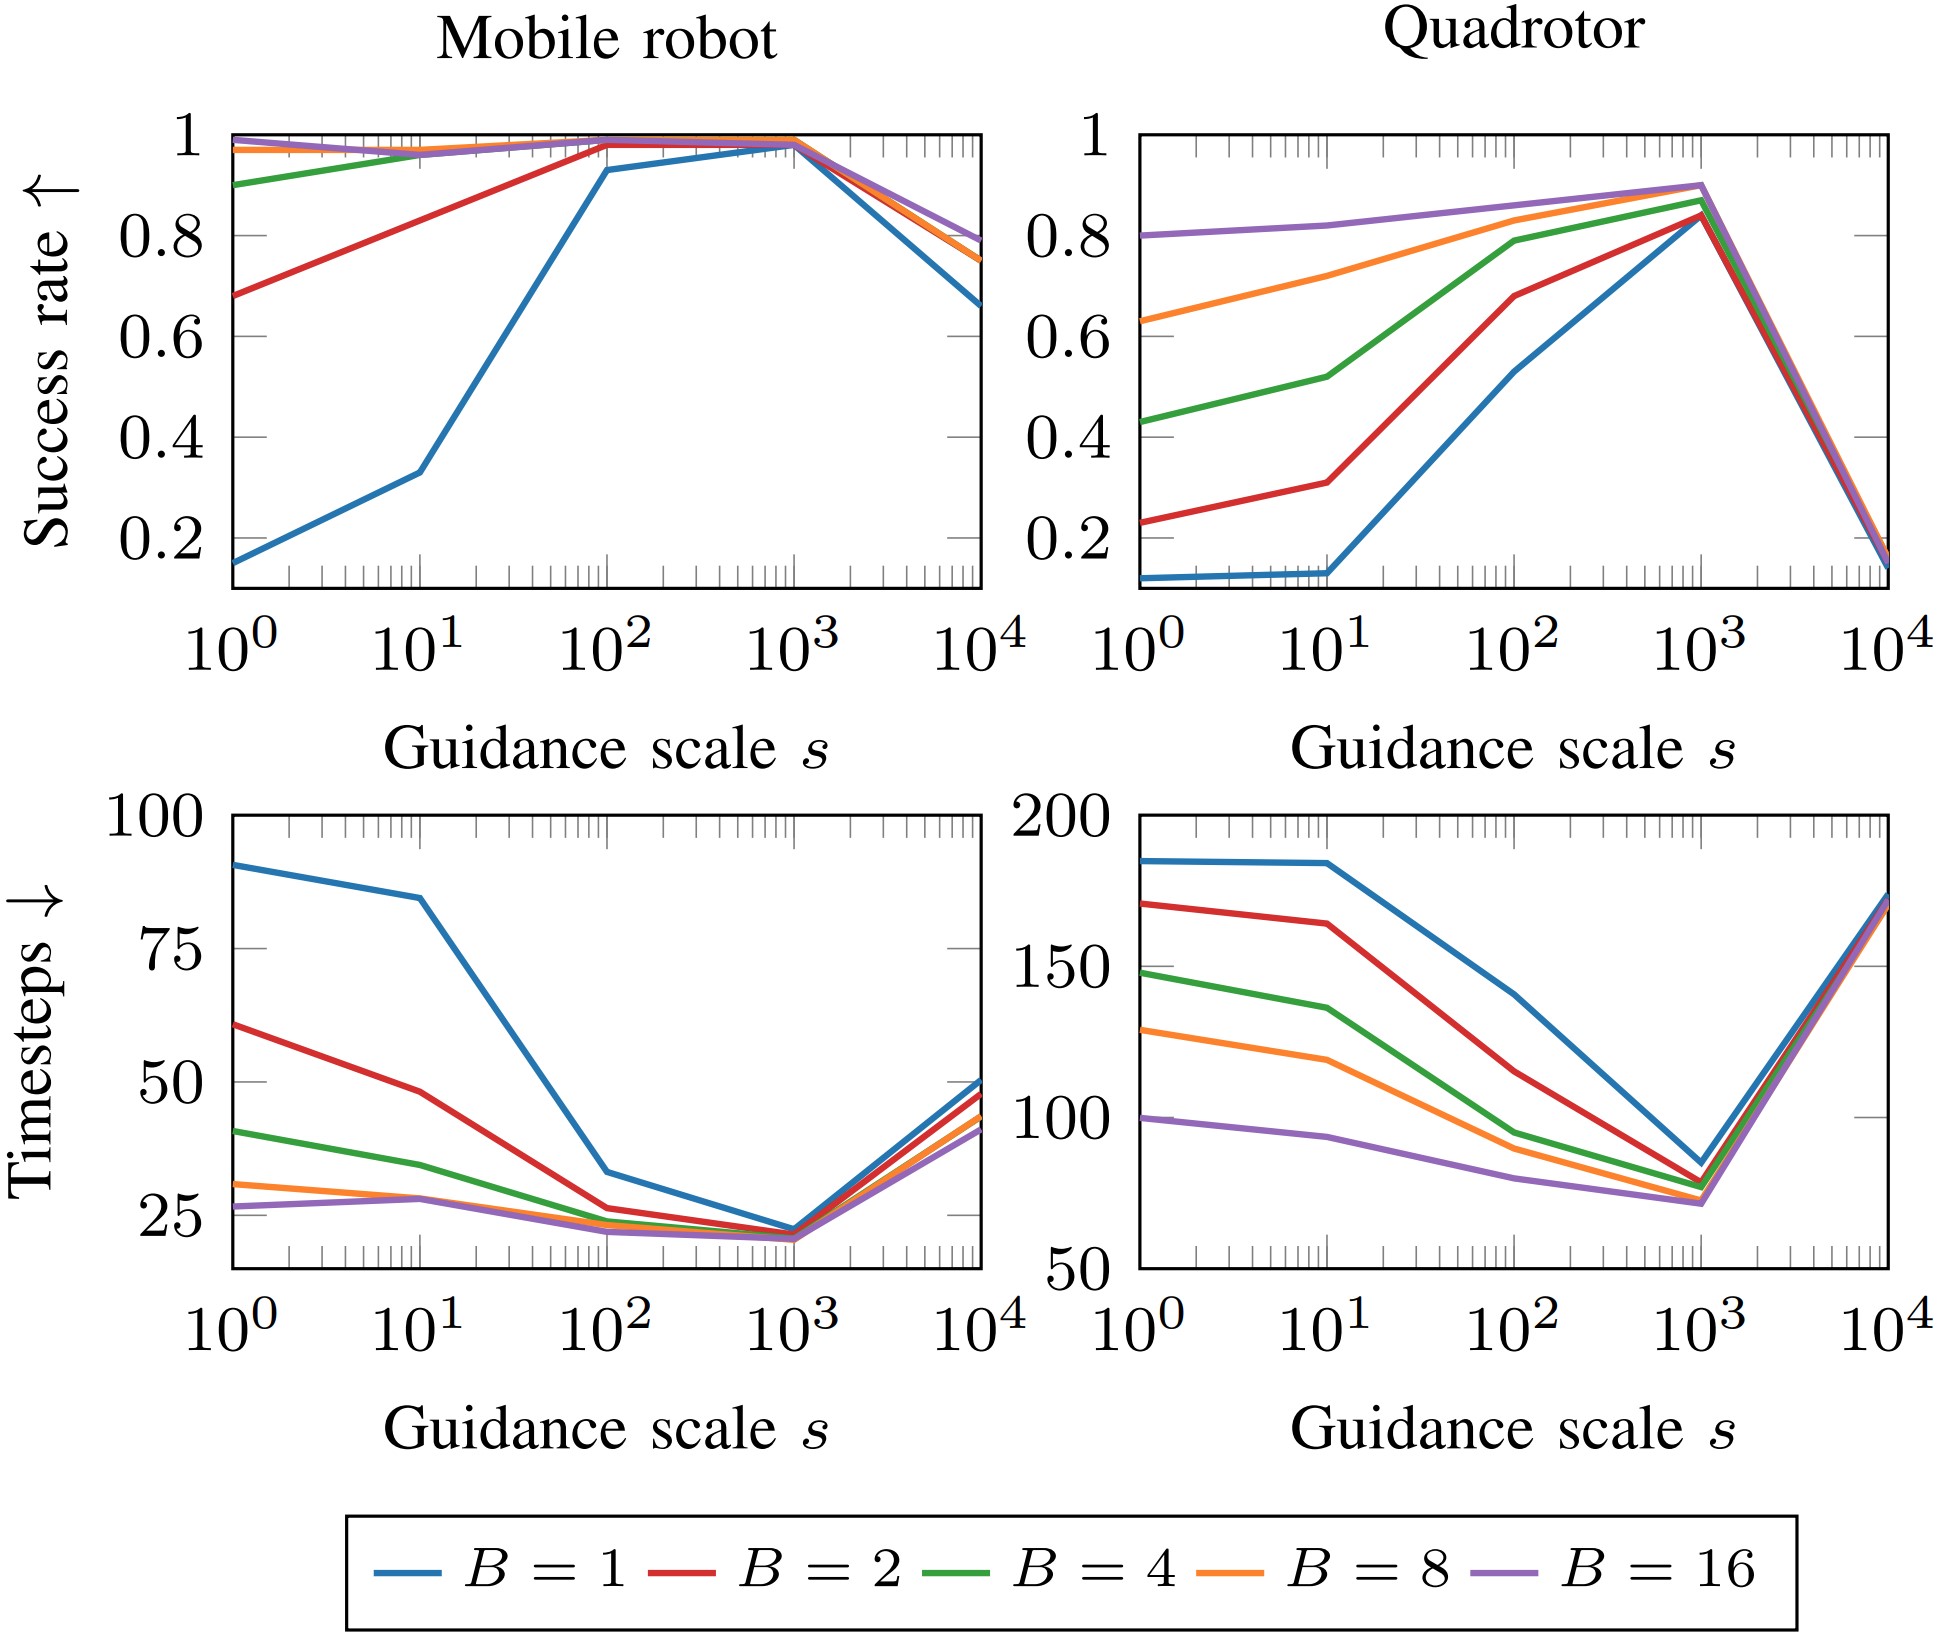
Safe Offline Reinforcement Learning using Trajectory-Level Diffusion Models
Ralf Römer, Lukas Brunke, Martin Schuck, and Angela P. Schoellig
In ICRA Workshop on Back to the Future: Robot Learning Going Probabilistic, 2024
2023
-
RA-L 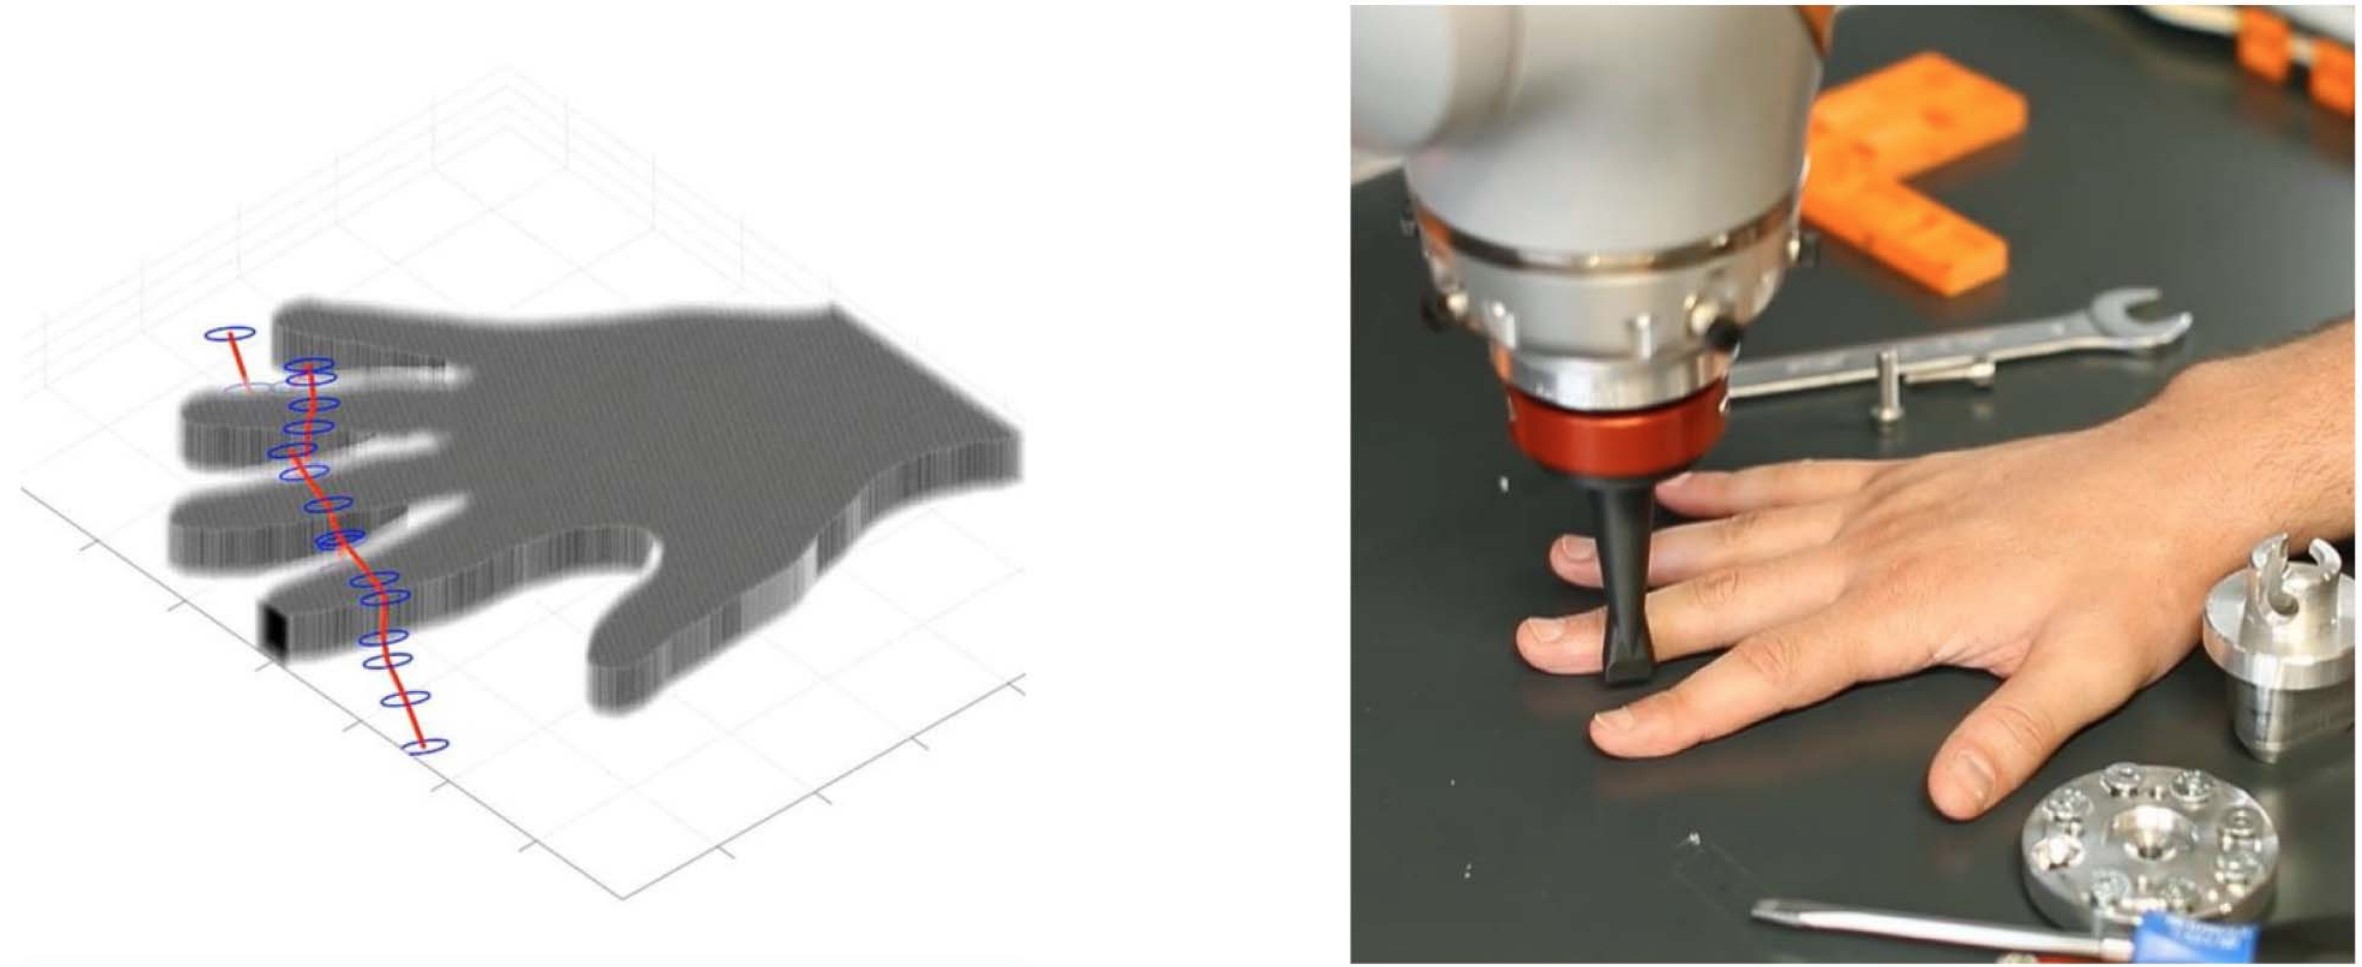
Vision-Based Uncertainty-Aware Motion Planning based on Probabilistic Semantic Segmentation
Ralf Römer*, Armin Lederer*, Samuel Tesfazgi, and Sandra Hirche
IEEE Robotics and Automation Letters (RA-L), 2023
-
Thesis 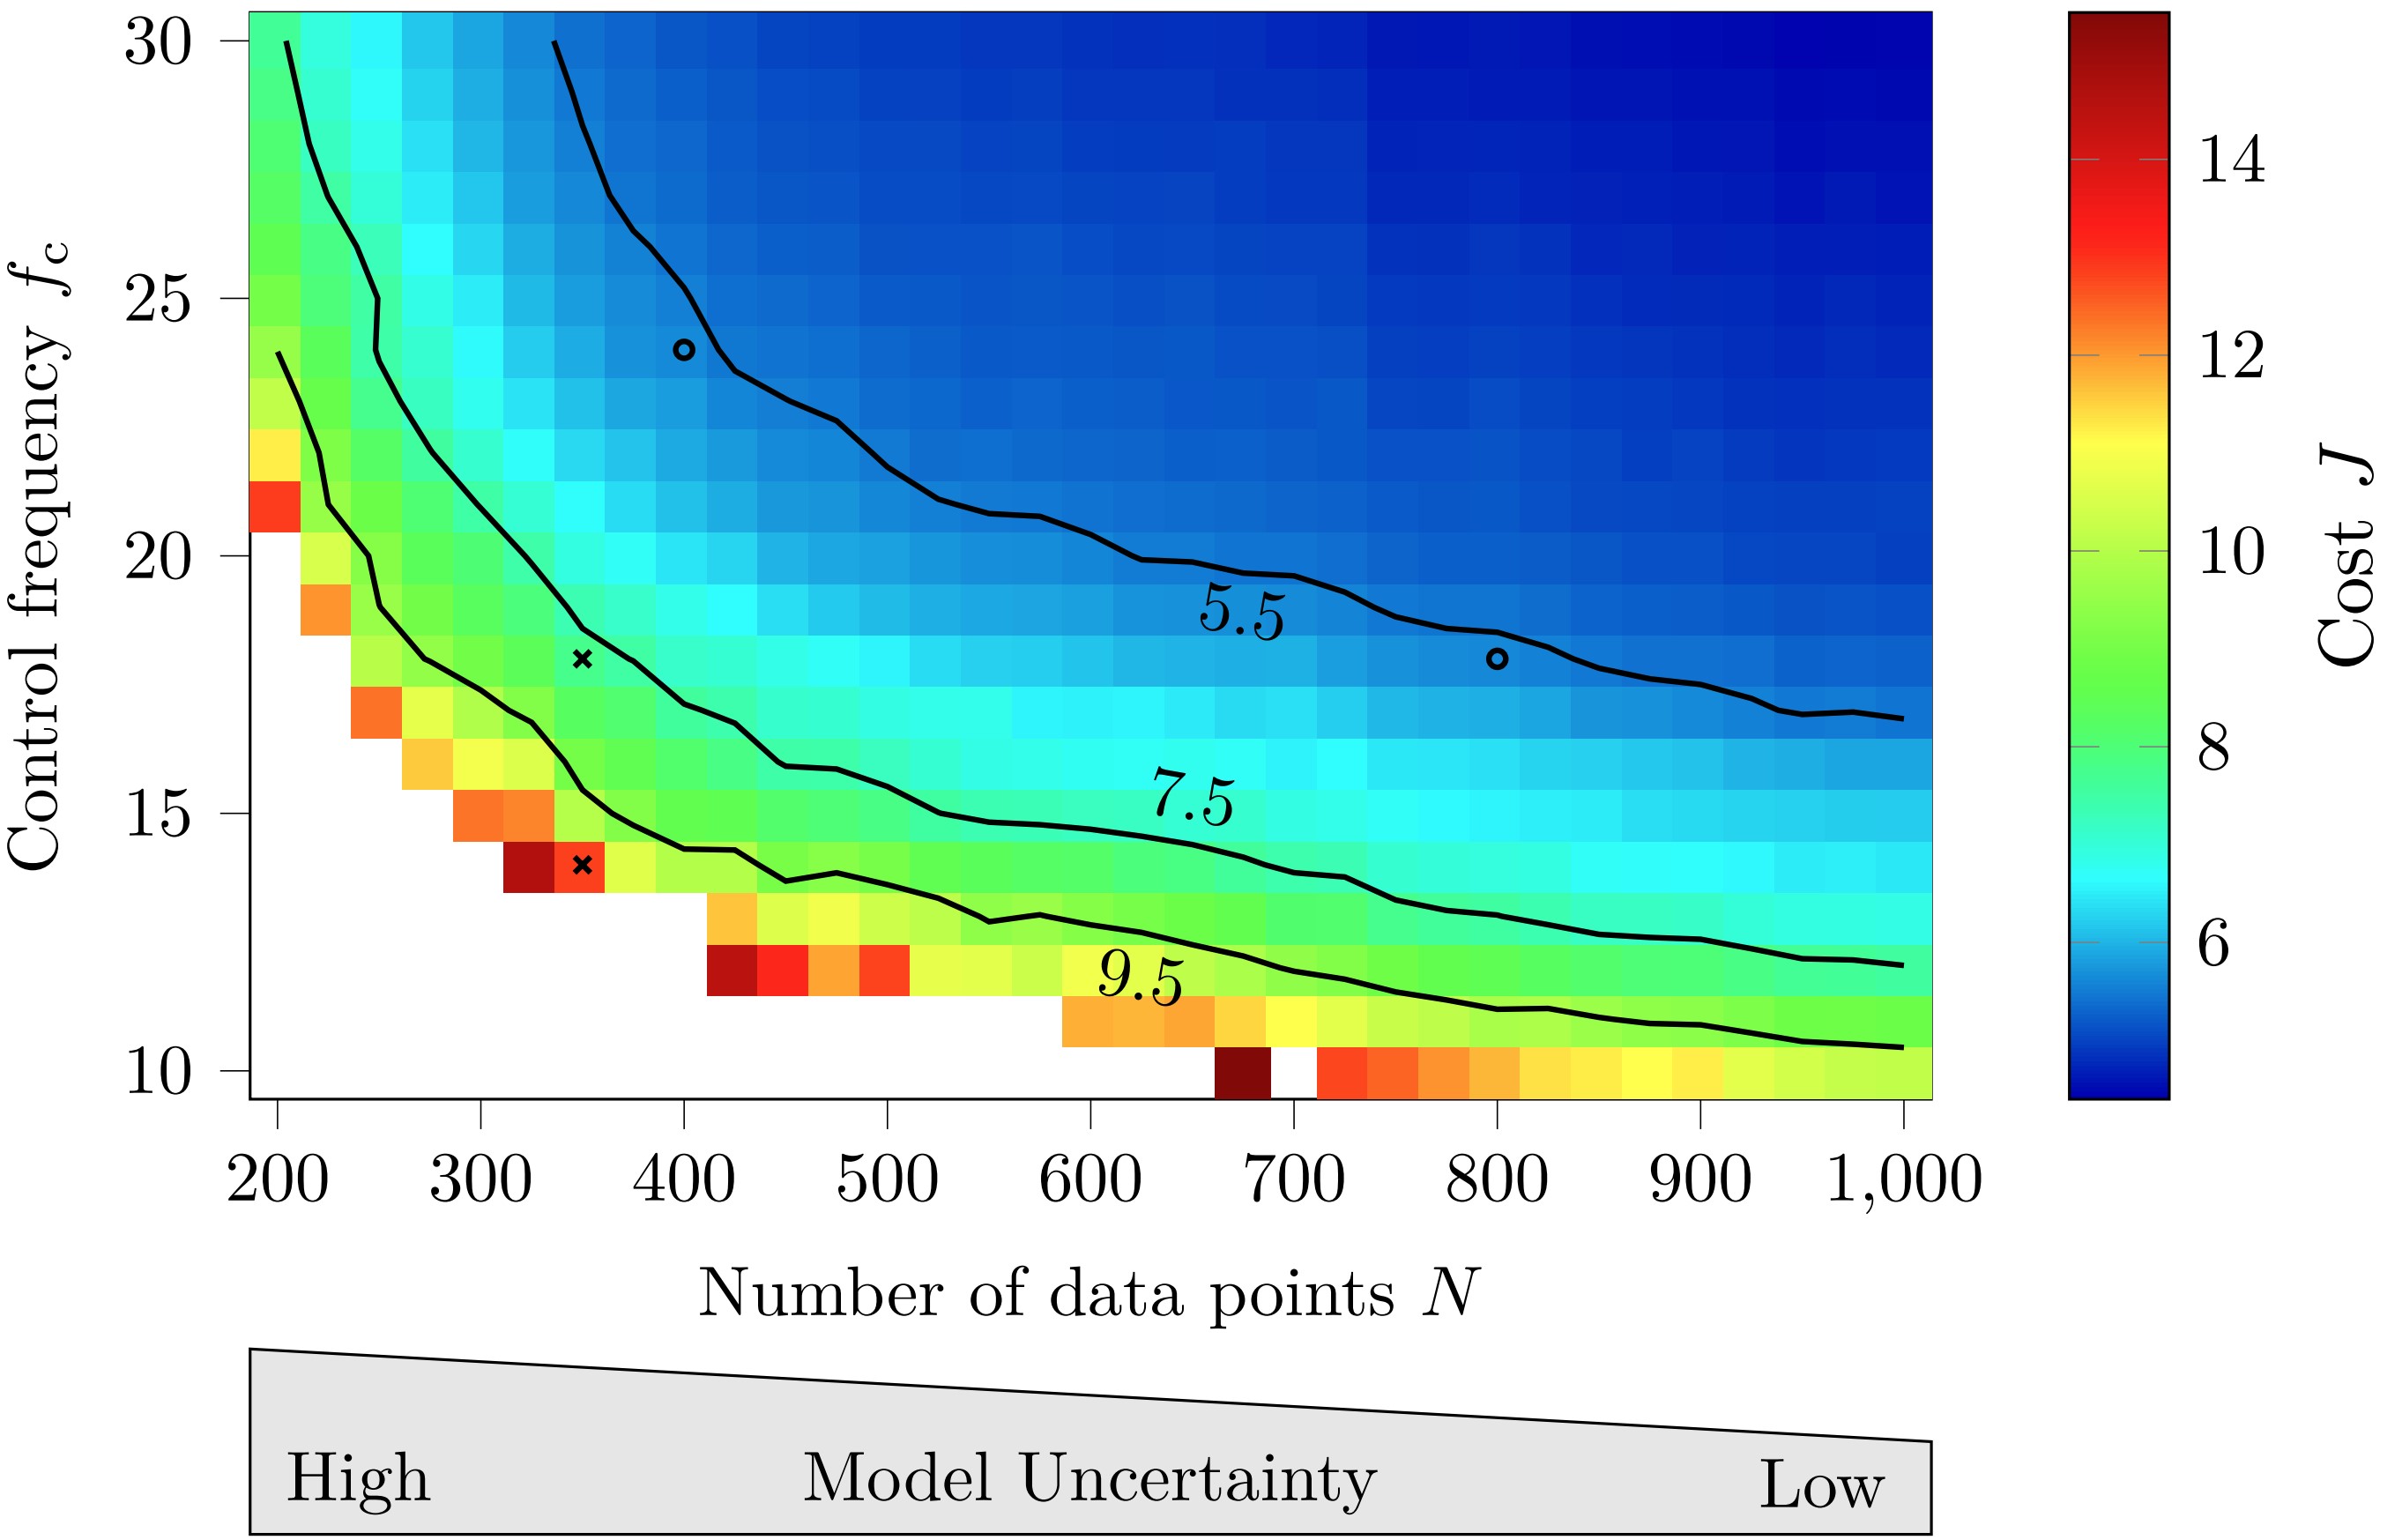
The Role of Control Frequency for the Stability and Closed-Loop Performance of Uncertain Systems
Ralf Römer
Technical University of Munich, 2023
Supervisors: Lukas Brunke, Dr. SiQi Zhou, Prof. Angela P. Schoellig
2022
-
ACC 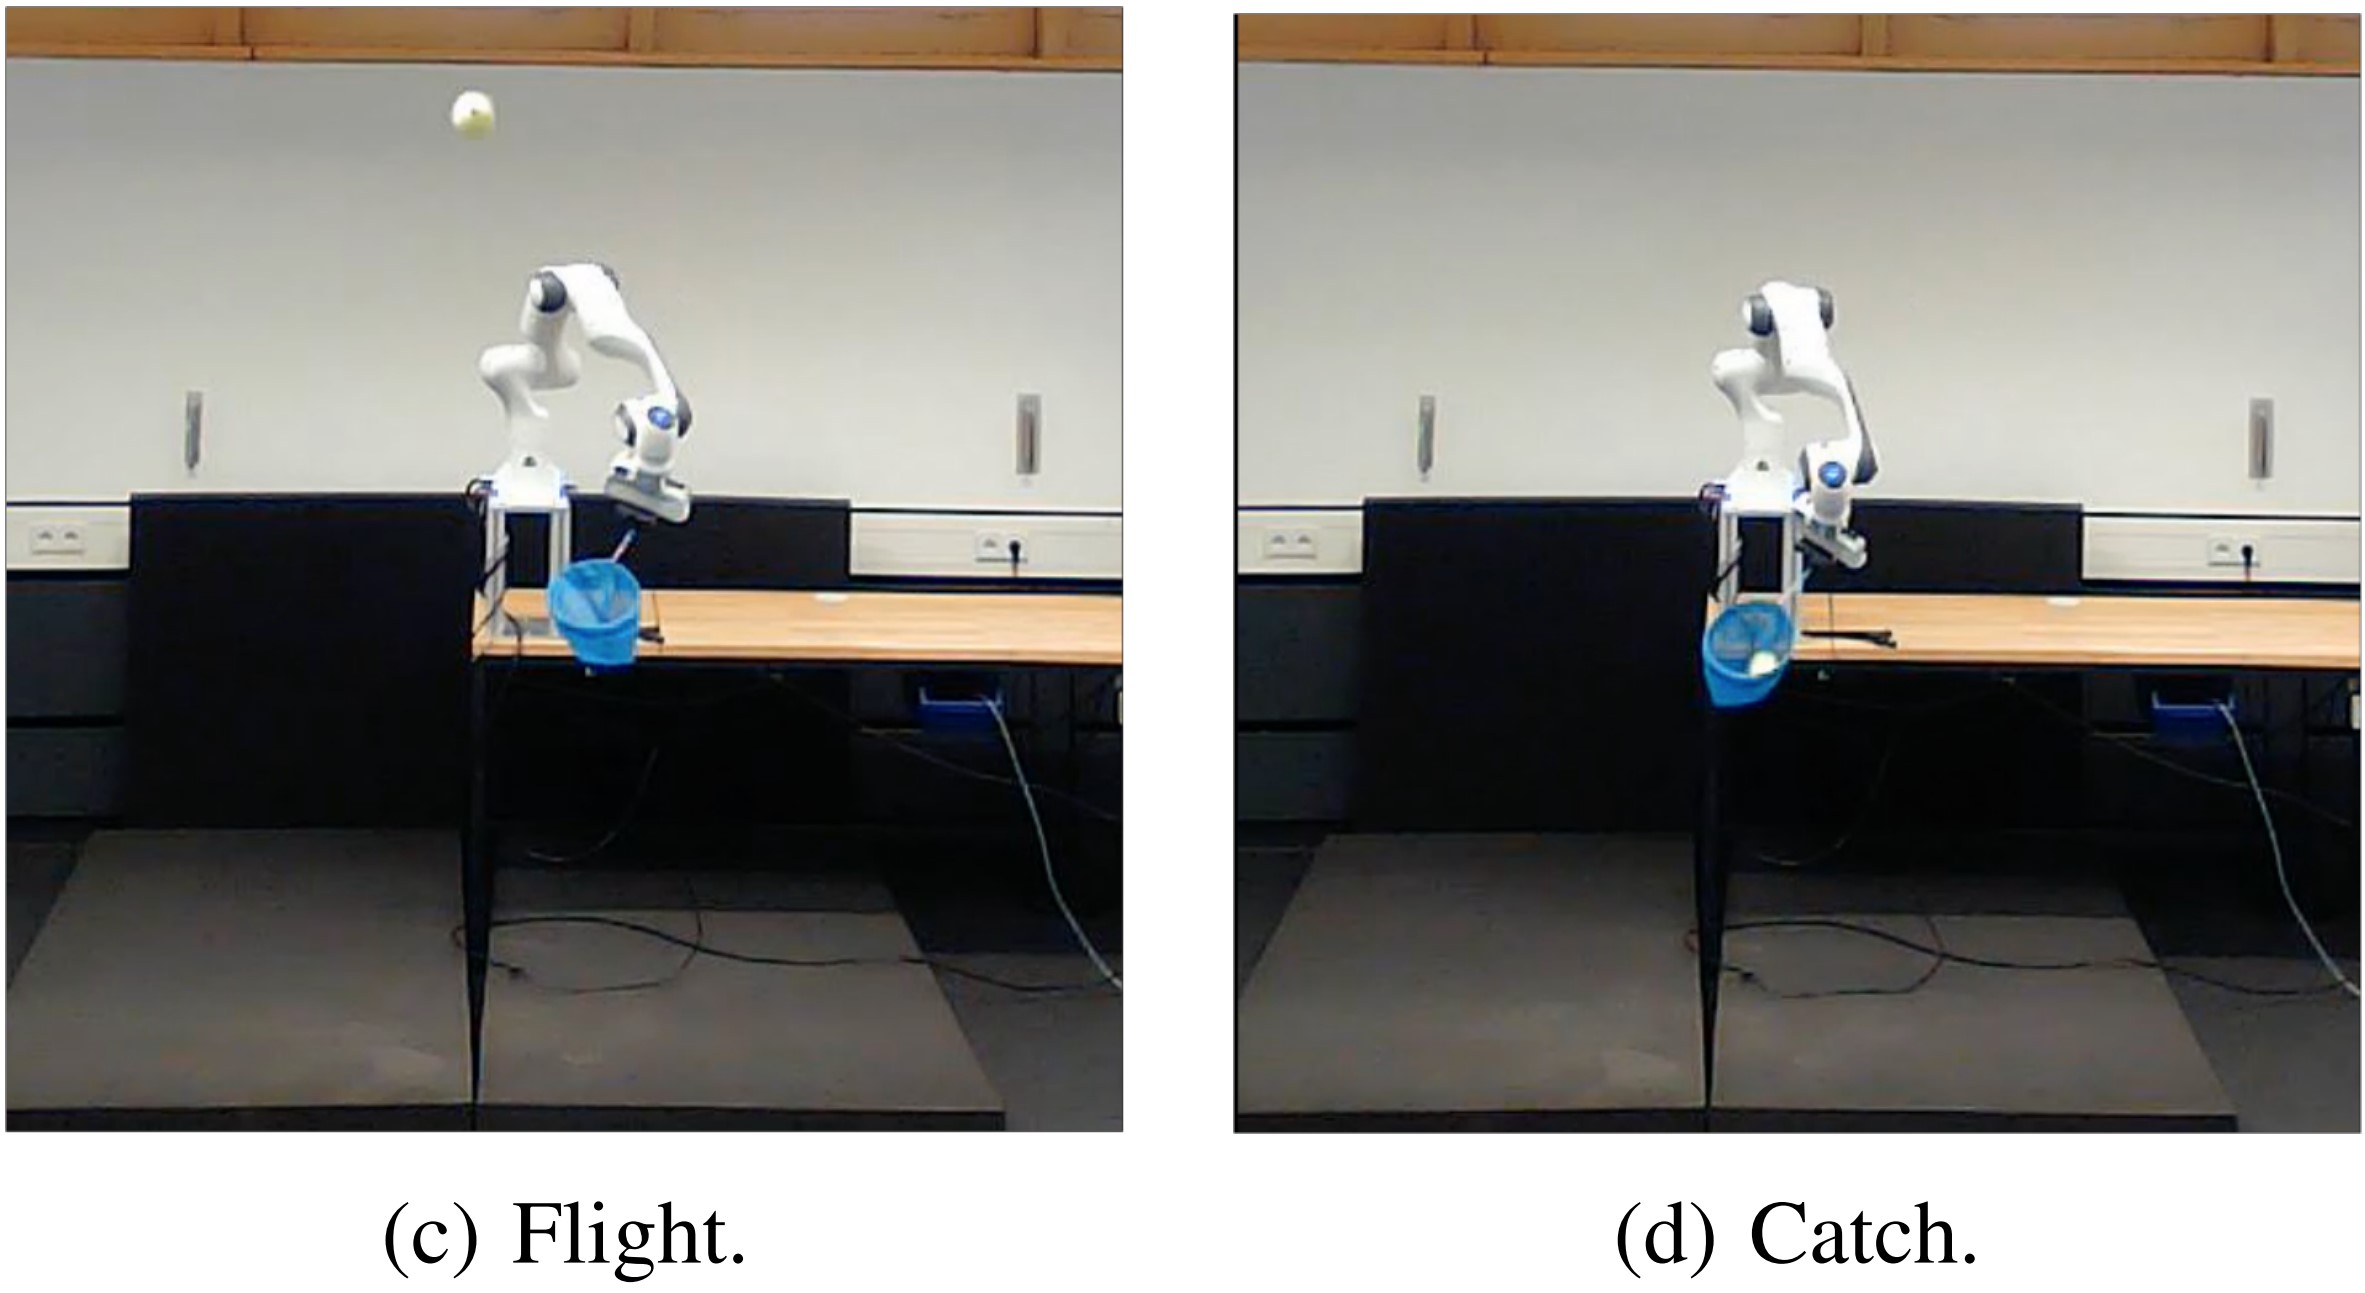
Catching Objects with a Robot Arm using Model Predictive Control
T. Gold, Ralf Römer, Andreas Völz, and Knut Graichen
In American Control Conference (ACC), 2022