Ralf Römer

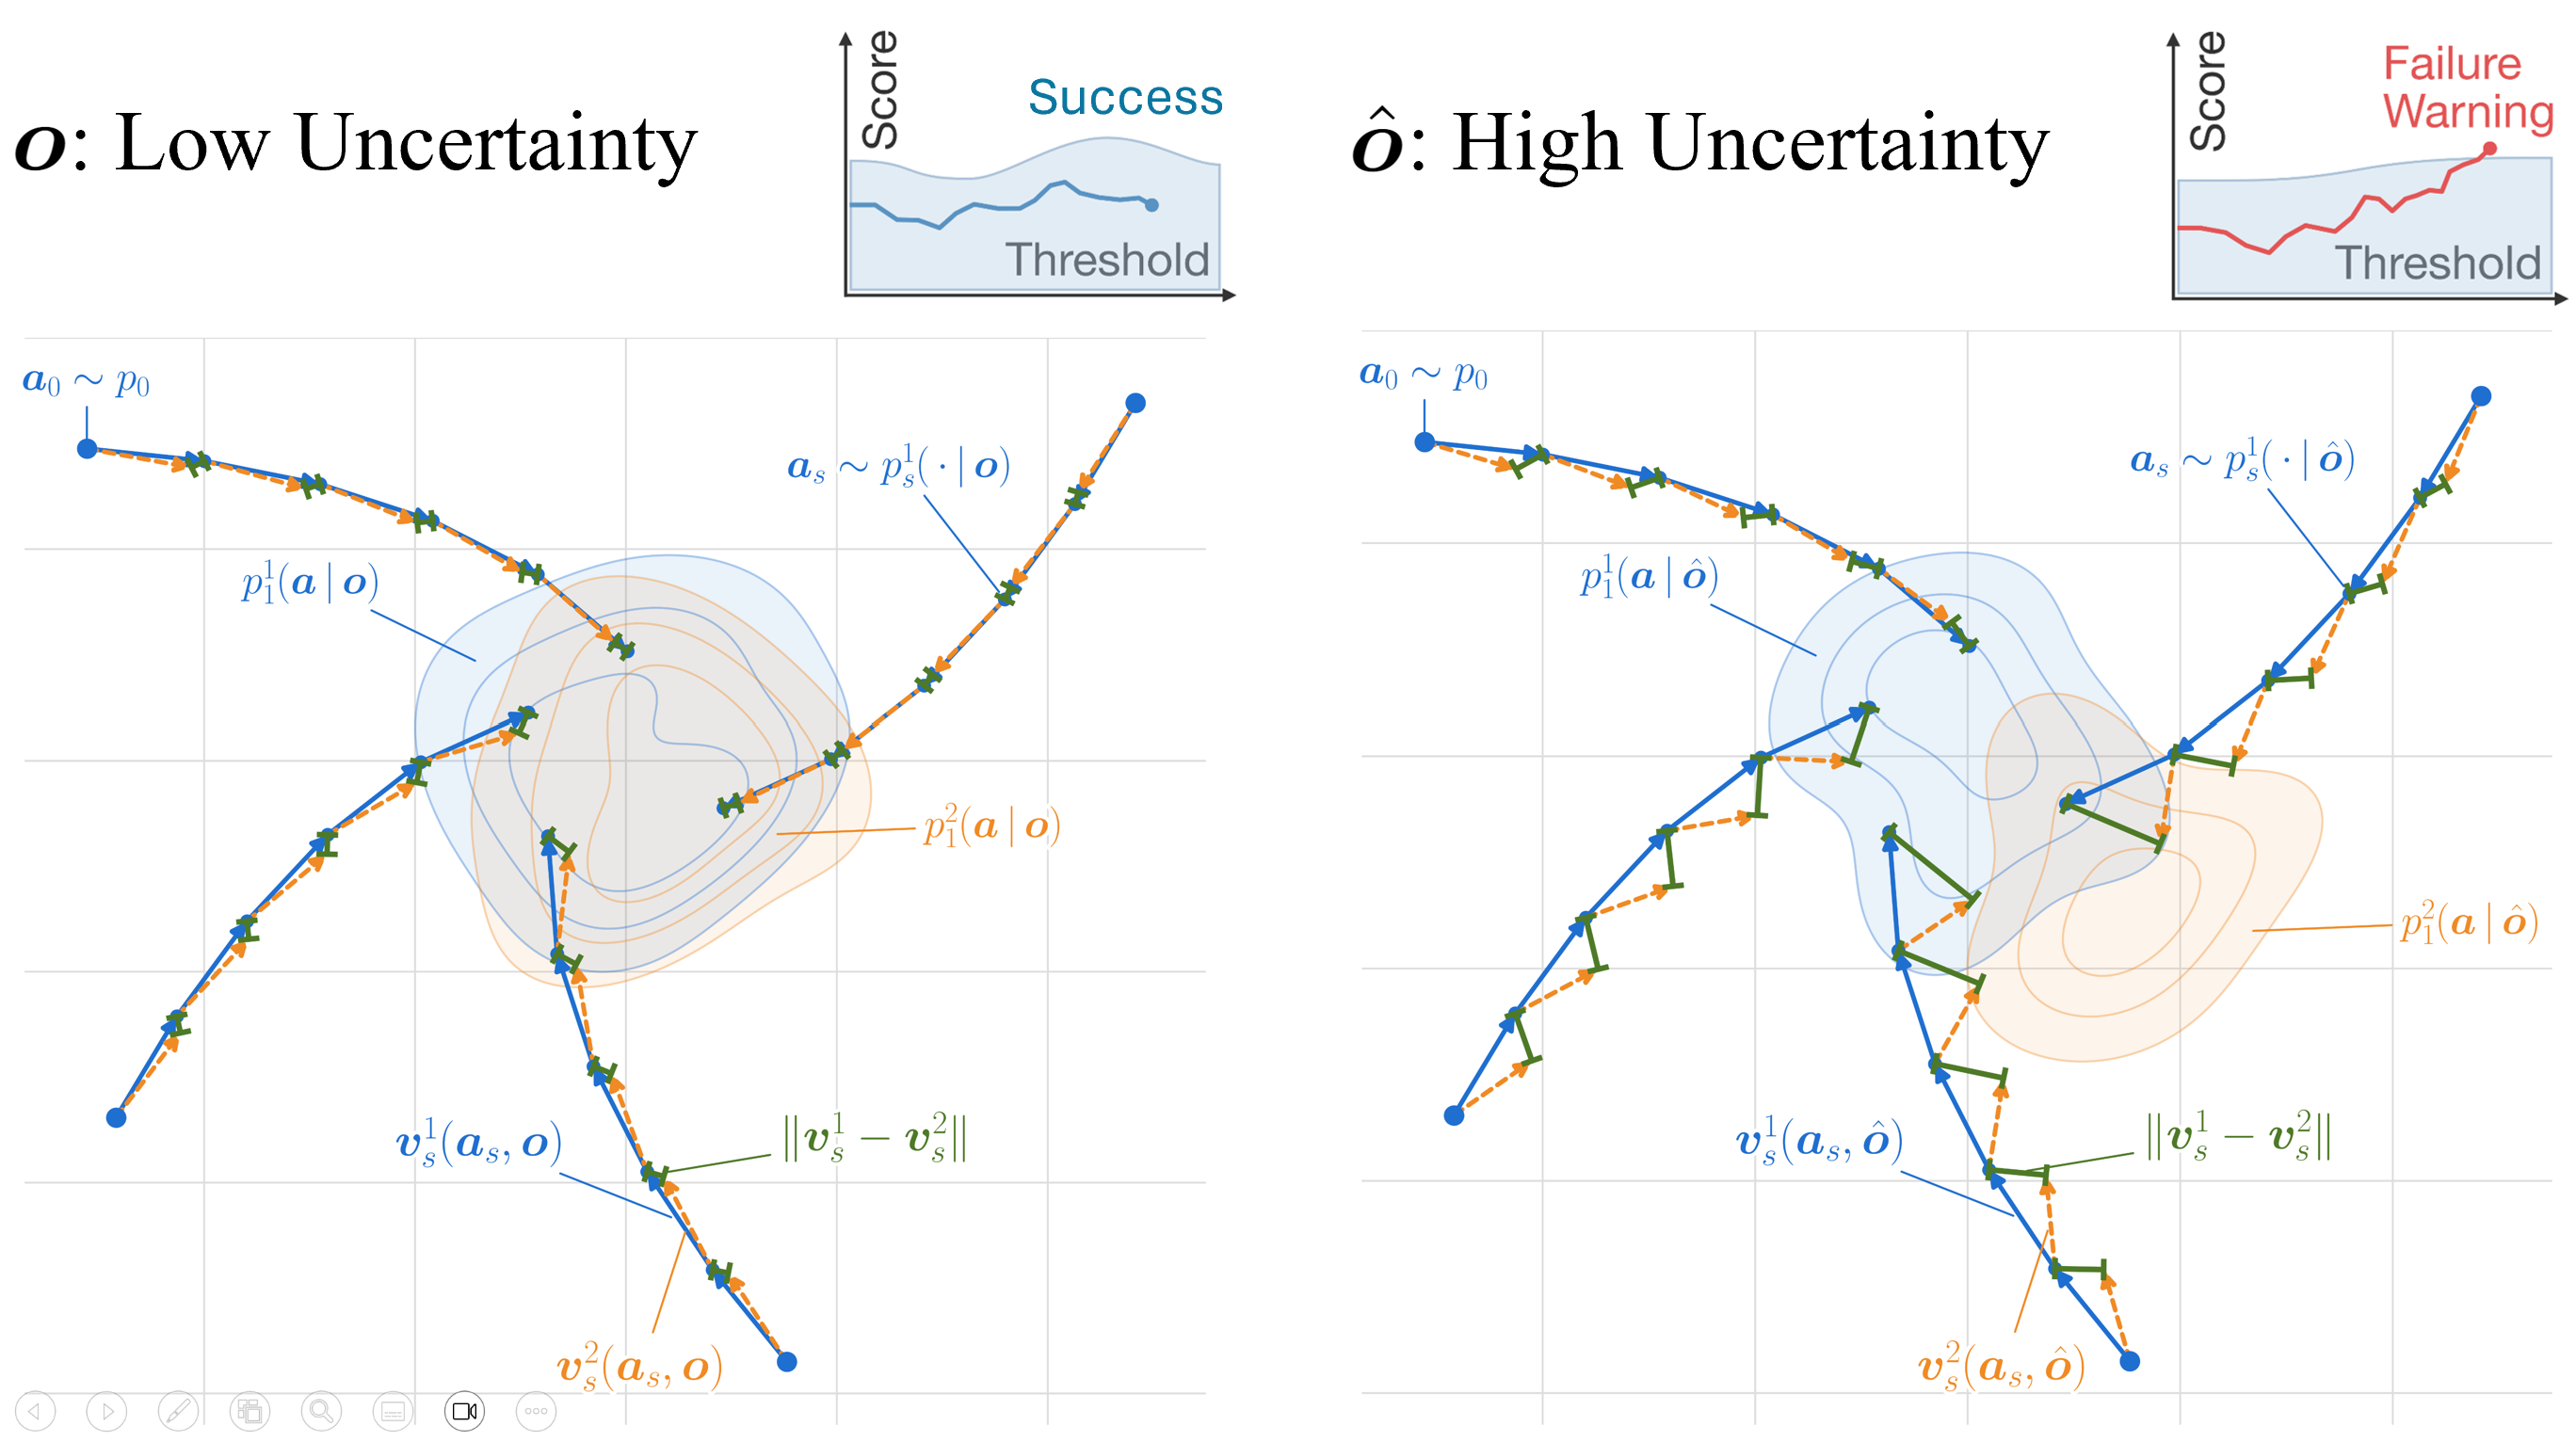
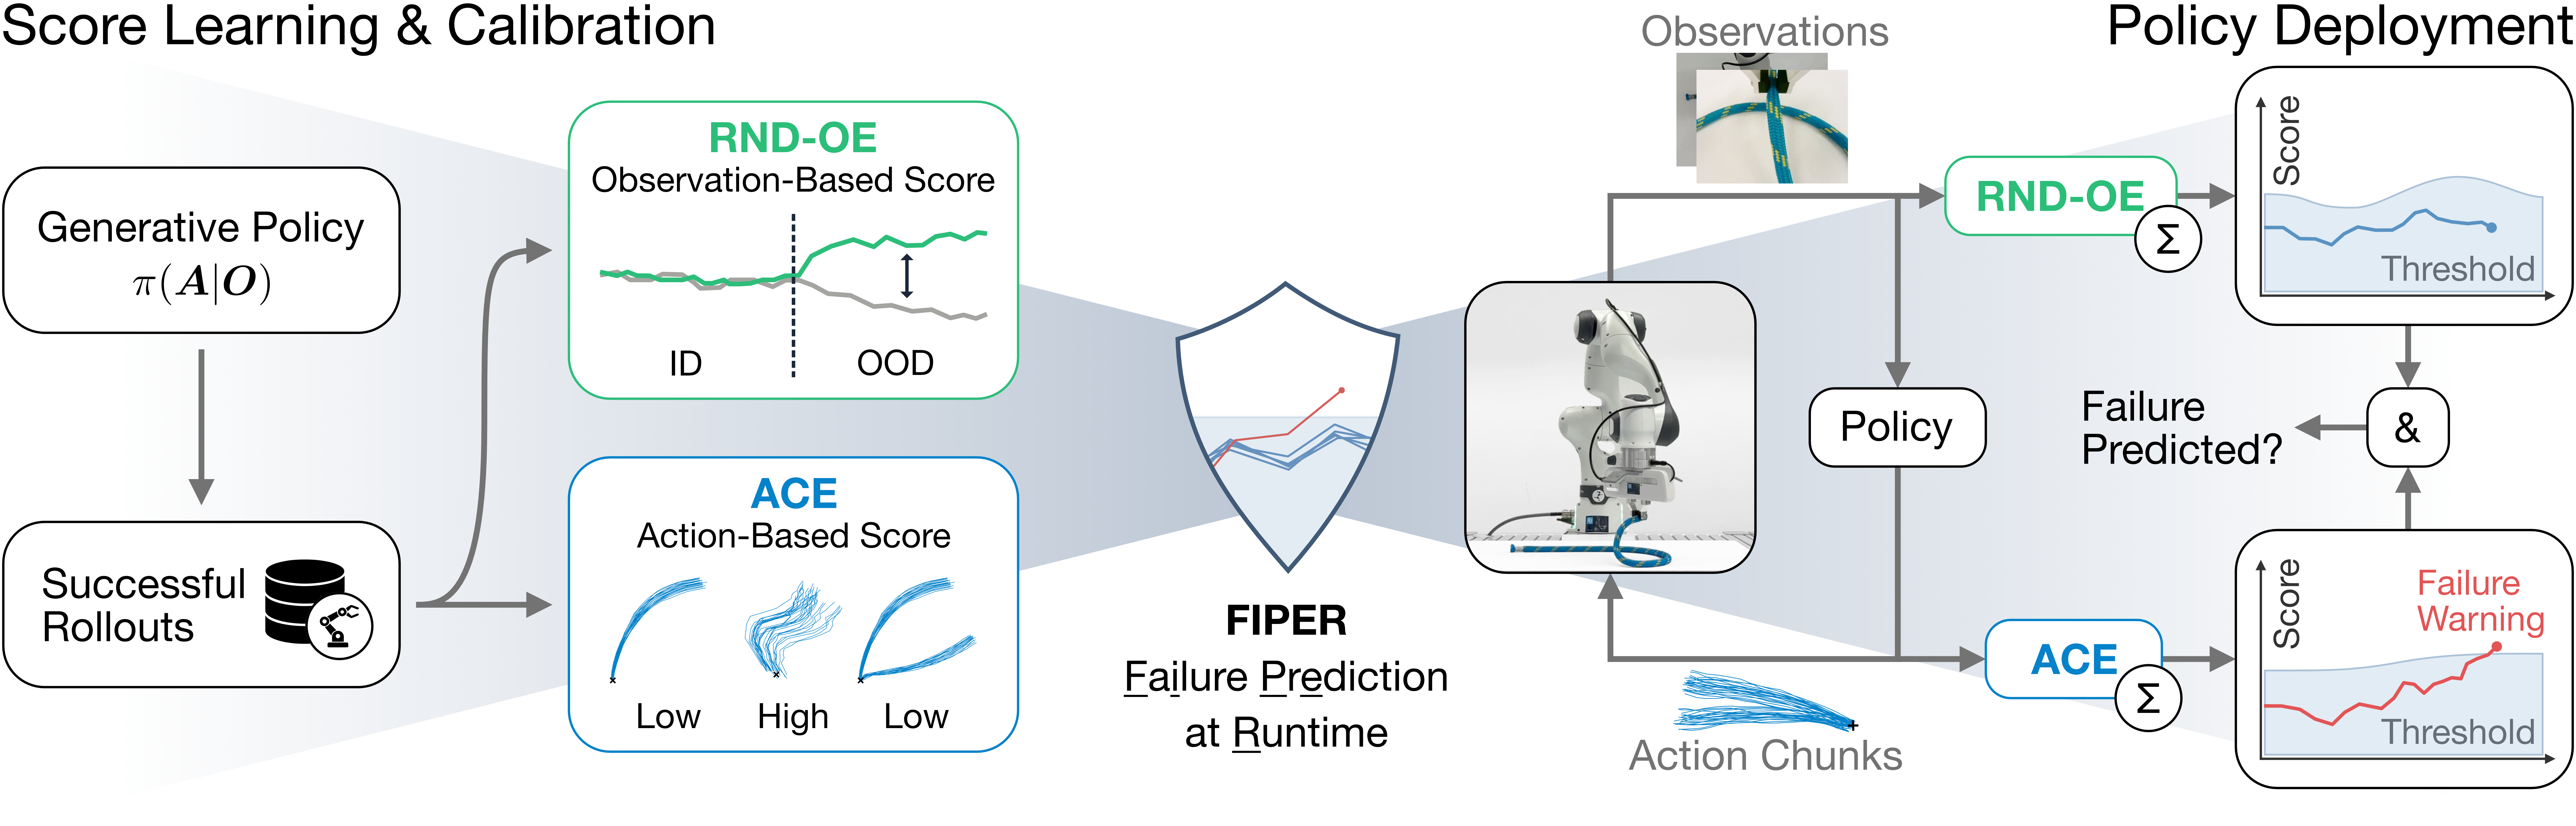
I am a PhD student at the Technical University of Munich (TUM) in the Learning Systems and Robotics Lab (LSY), advised by Prof. Angela Schoellig. Recently, I spent time as a visiting researcher at ETH Zurich in the Learning and Adaptive Systems Group, advised by Prof. Andreas Krause. My research focuses on physical AI: enabling robots to safely and autonomously improve throughout their operational lifetimes, making them reliable and effective for deployment in real-world settings. To this end, I develop methods for uncertainty-aware post-training and continual learning for generalist robot policies (e.g., VLAs, WAMs).
Before joining LSY, I obtained a Master’s degree in Electrical and Computer Engineering at TUM in 2023 and a Bachelor’s degree in Mechatronics at FAU Erlangen-Nuremberg in 2020, funded by the German Academic Scholarship Foundation. During my studies, I spent a semester at EPFL and conducted research in machine learning for robotic throwing with Prof. Aude Billard. Previously, I also worked with Prof. Sandra Hirche at TUM and with Prof. Knut Graichen at FAU. In 2021, I did a research internship in optimal control for autonomous driving at Bosch Research in Renningen, Germany.
Student Supervision: I am always open to supervising excellent and ambitious Master and Bachelor students for a semester project or thesis. You can find a non-exhaustive list of potential topics here. If you want to work with me, please send me an email describing your area of interest and attach your CV and up-to-date transcripts.
News
| Jul 2026 | Gave an invited talk at the RSS Workshop on Trustworthy Embodied Foundation Models. At the Diffusion for Robot Learning Workshop, we received the best paper award! Impressions. |
|---|---|
| Jun 2026 | Gave an invited talk at the Robot Learning Lab at the University of Freiburg. Impressions. |
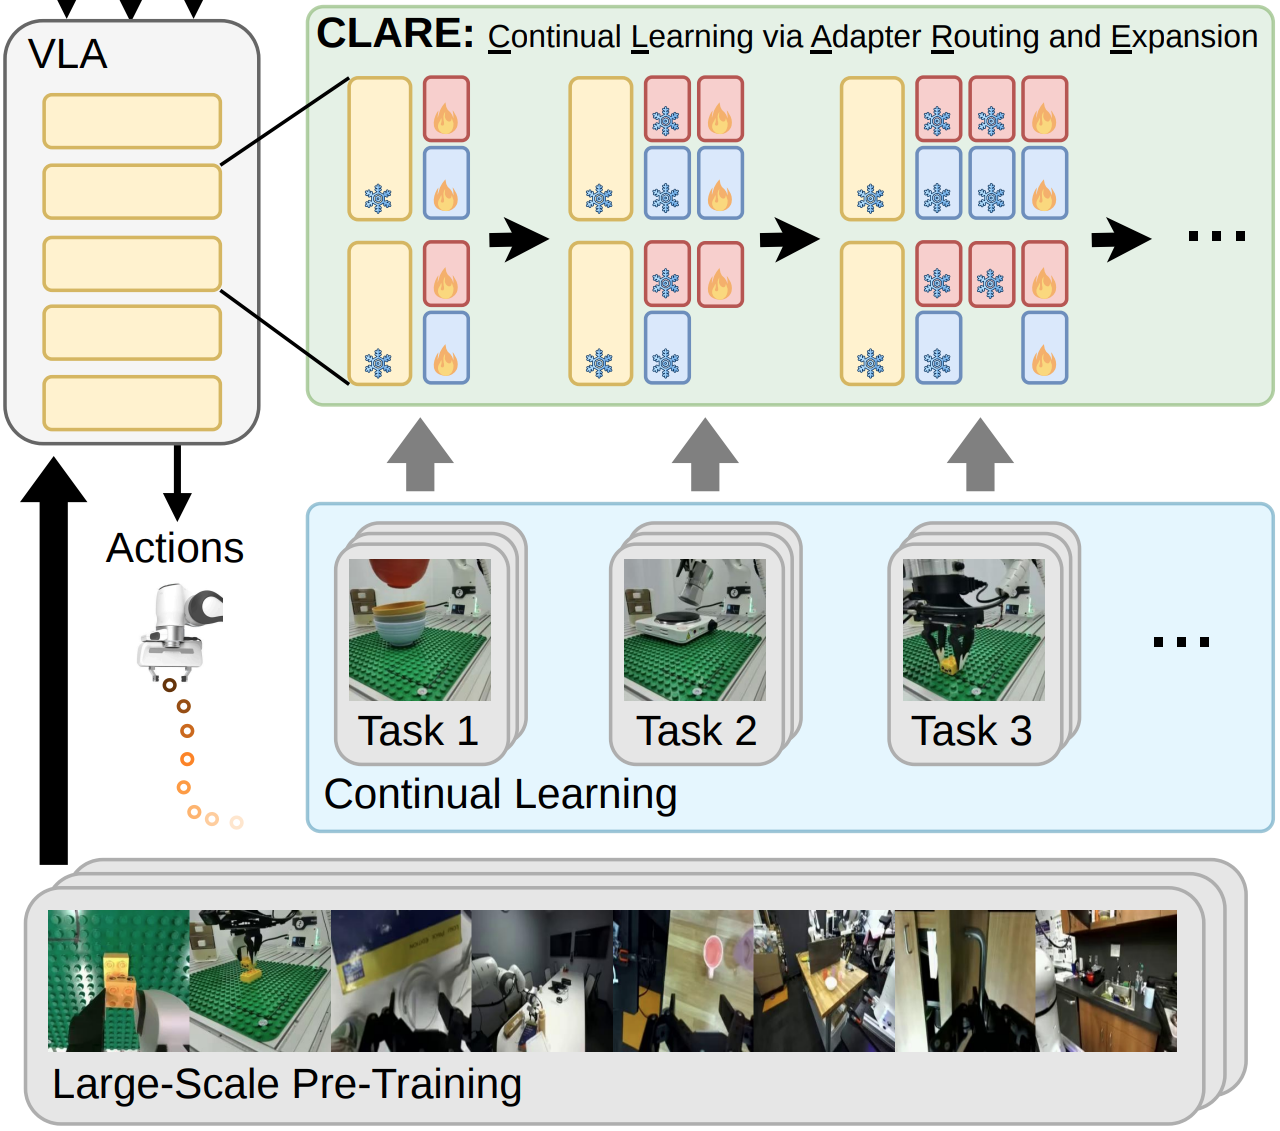
| Apr 2026 | Our paper “CLARE: Continual Learning for Vision-Language-Action Models via Autonomous Adapter Routing and Expansion” has been accepted to RA-L. Website. |
| Apr 2026 | Started as a visiting researcher at the Learning and Adaptive Systems Group at ETH Zurich, hosted by Prof. Andreas Krause. |
| Mar 2026 | Our paper “CRISP - Compliant ROS2 Controllers for Learning-Based Manipulation Policies and Teleoperation” has been accepted to RA-P. Website. |